View methods side by side.
Choose up to four methods. Add them using the search and share the comparison by copying its link.
| Criterion | 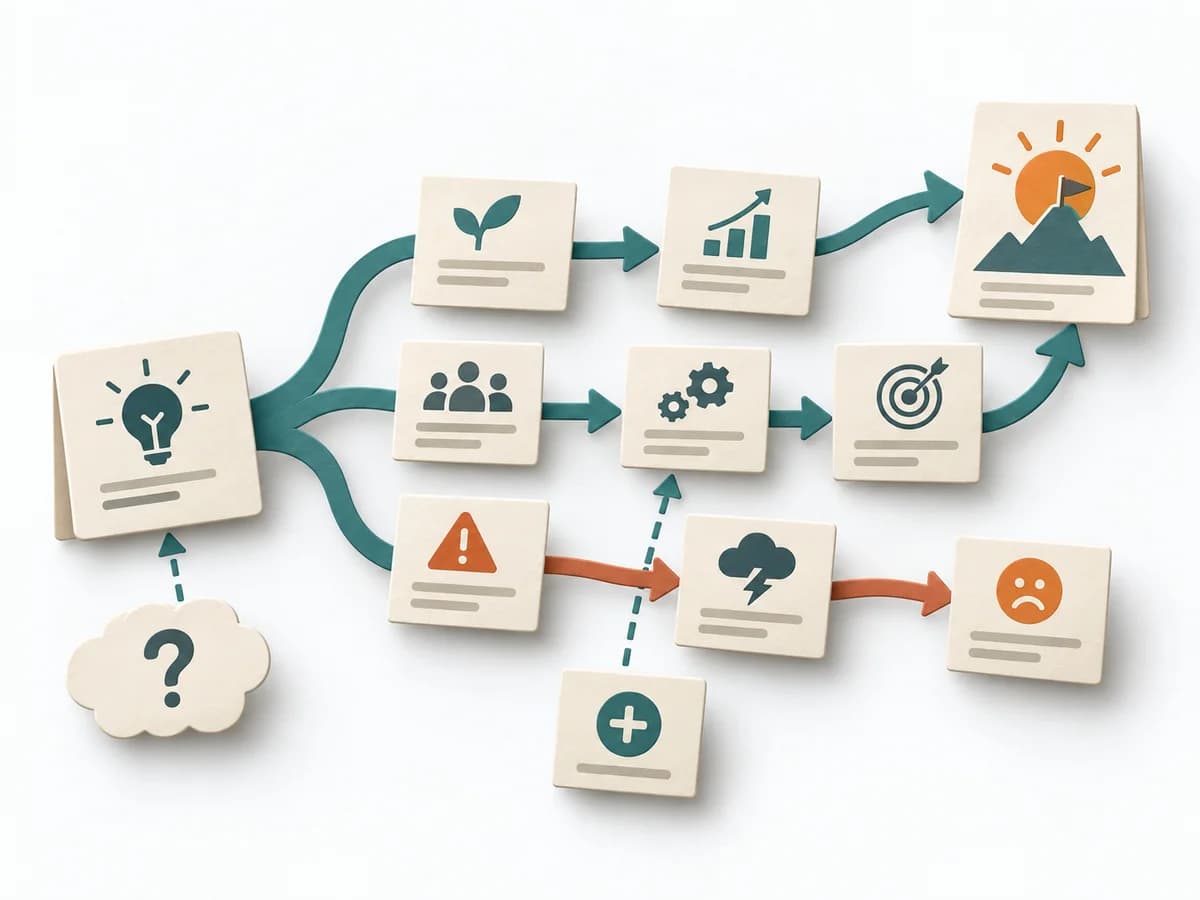 Systems Thinking Future Reality Tree | 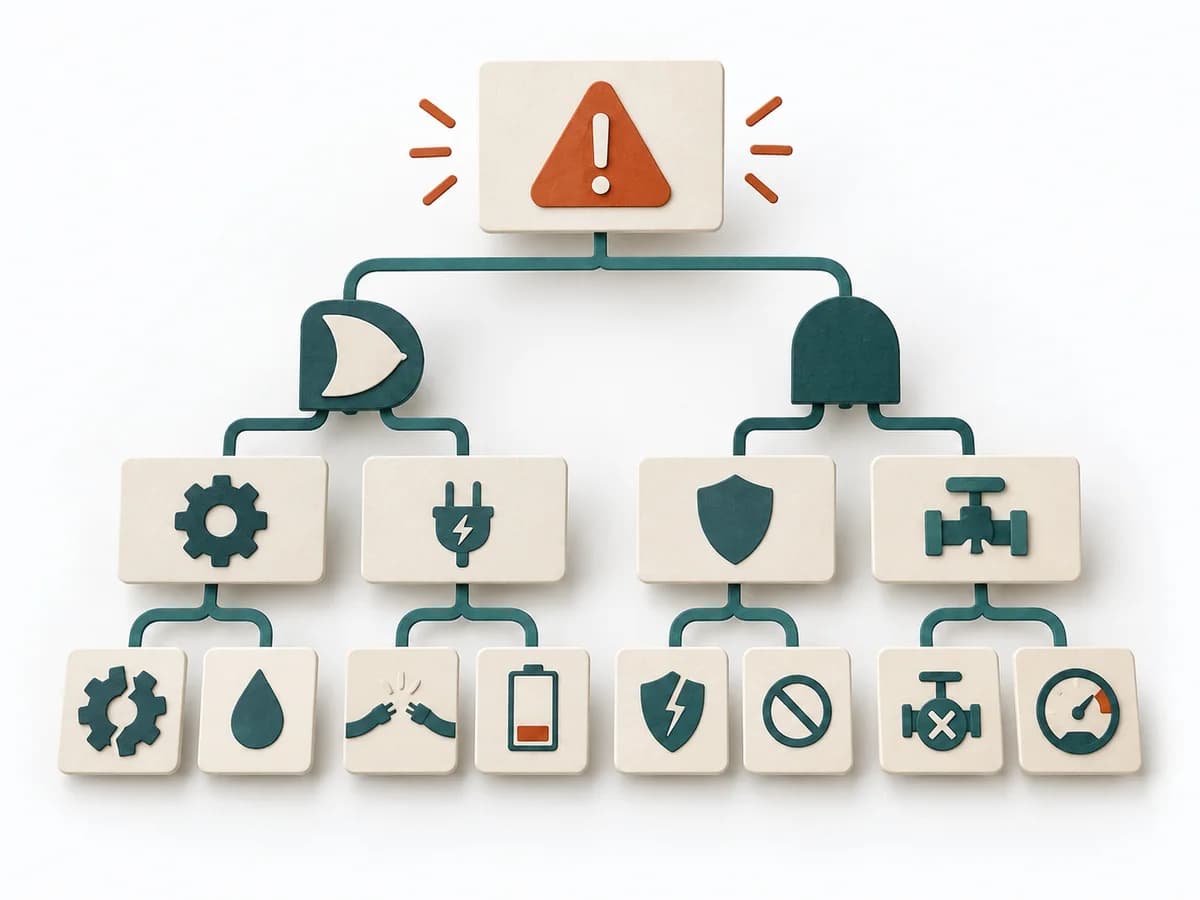 Operations Fault Tree Analysis | 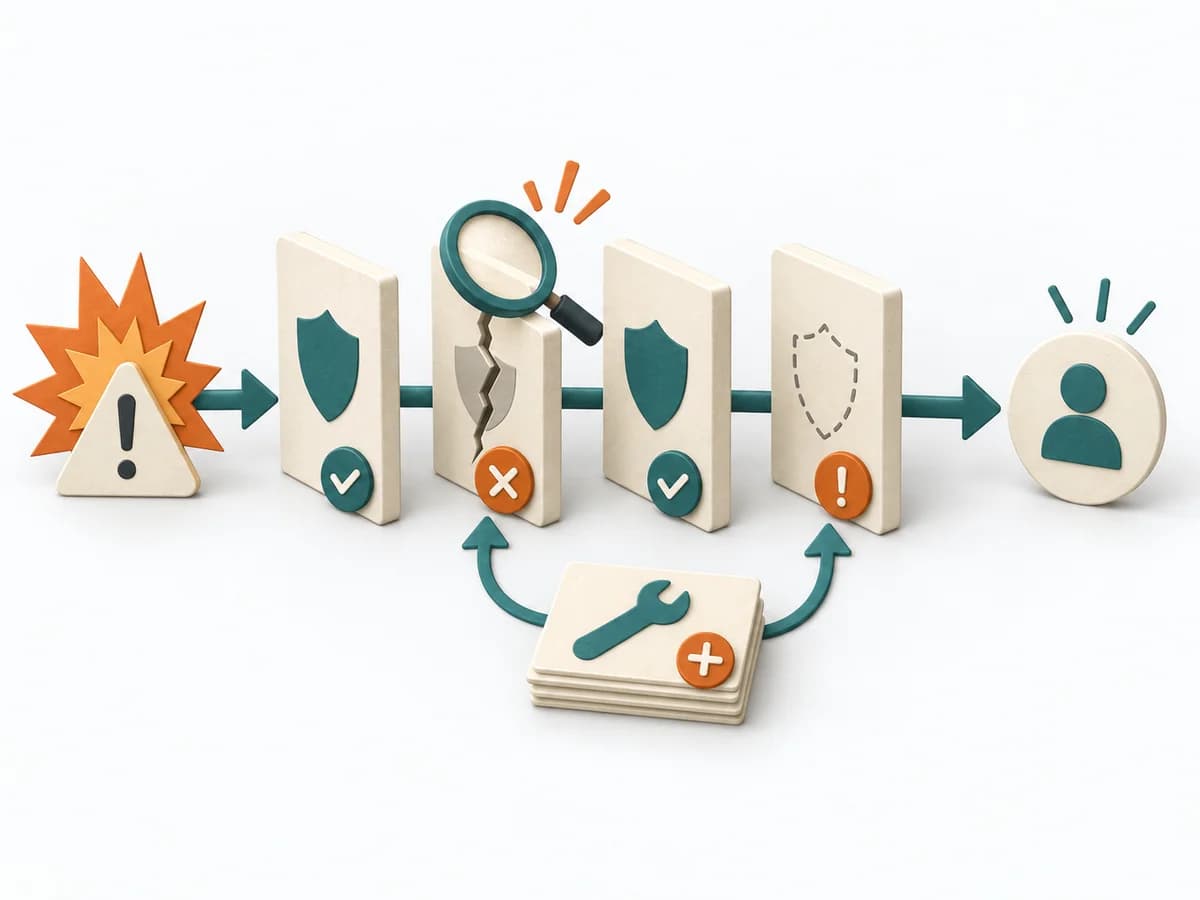 Operations Barrier Analysis |
|---|---|---|---|
Purposedifferent | A Future Reality Tree shows how desired actions are meant to lead to a better system state. The method checks whether a path of change holds together logically before time flows into implementation. | For a critical top event with several possible triggers, the method logically models failure paths. It makes visible which combinations of conditions can lead to damage. | For a risk that can only be managed through multiple layers of protection, the method examines the effectiveness of each barrier. It shows where safeguards are missing, too weak, or fail under real conditions. |
Complexitydifferent | High | High | Medium |
Timedifferent | 2-4 h | 2-6 h | 2-4 h |
Participantsdifferent | 3-8 | 3-8 | 2-6 |
Formatdifferent | Workshop | Workshop + async | Workshop + async |
Outputdifferent | Future Reality Tree, Negative Branches, Assumption List, Improved Injections | Fault Tree, Critical Paths, Cause Hypotheses, Control Actions | Barrier Inventory, Failure Analysis per Barrier, Action Backlog |
Tagsno overlap | Theory of ConstraintsSystems thinkingChange | RiskRoot causeSafety | Root causeSafetyIncident |
Often compared together
Methods with strong topical overlap with the current selection, not yet in the comparison.