View methods side by side.
Choose up to four methods. Add them using the search and share the comparison by copying its link.
| Criterion | 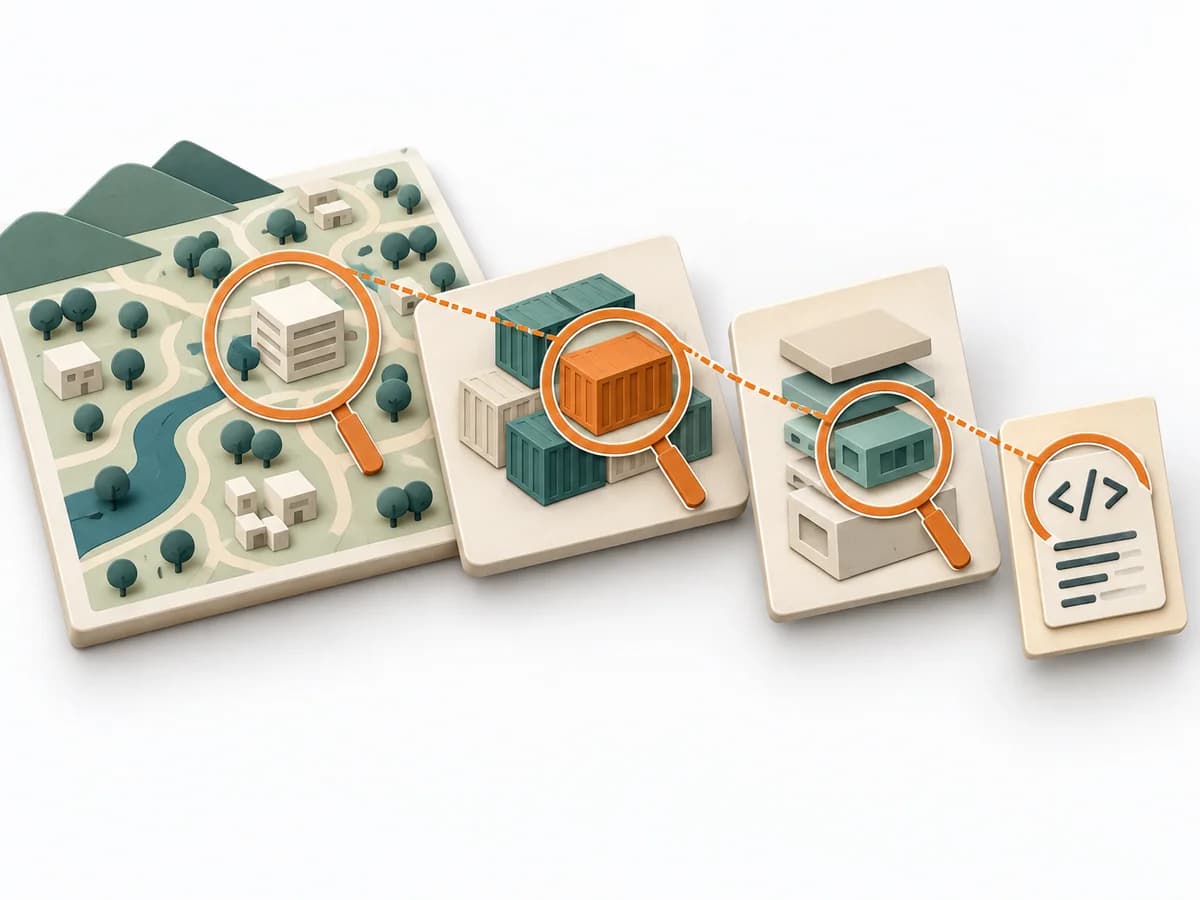 Architecture C4 Model | 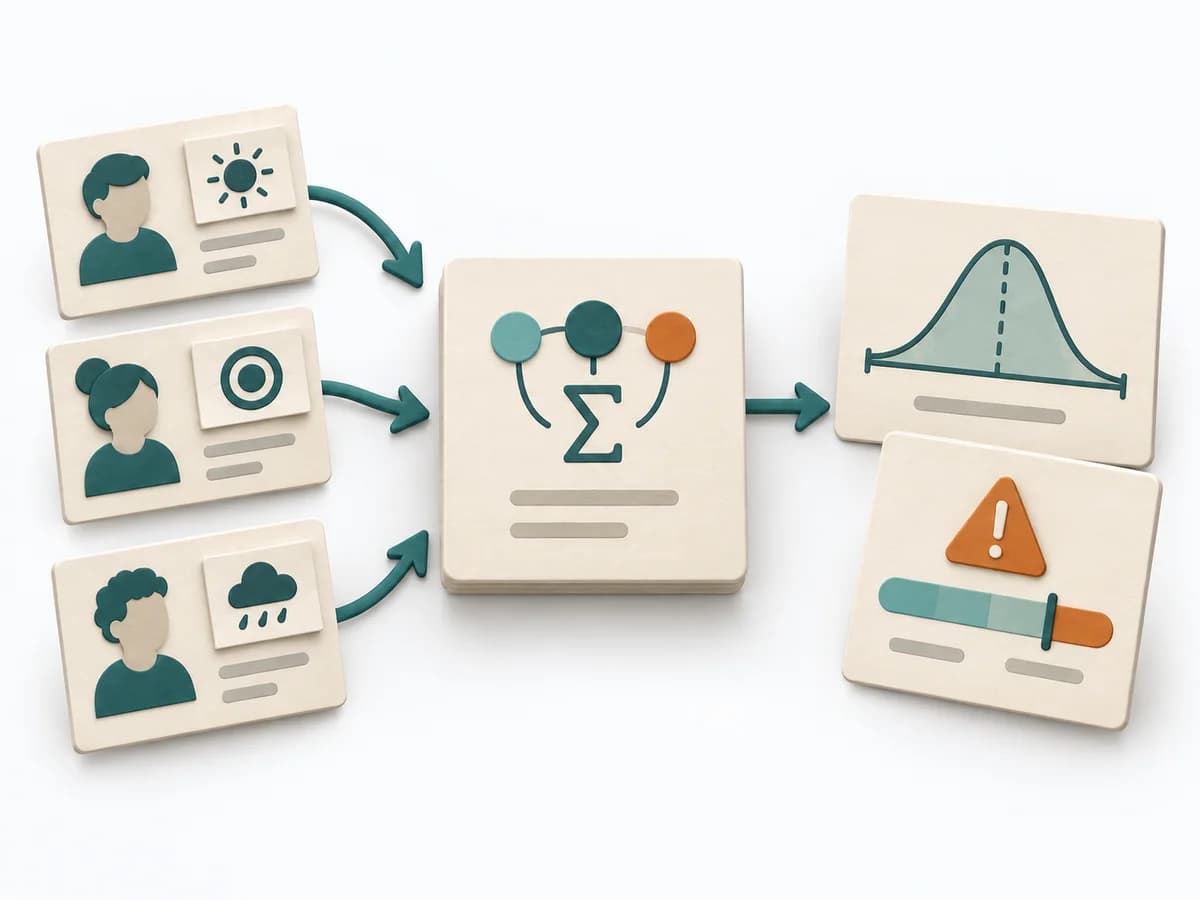 Decision Making PERT Estimation | 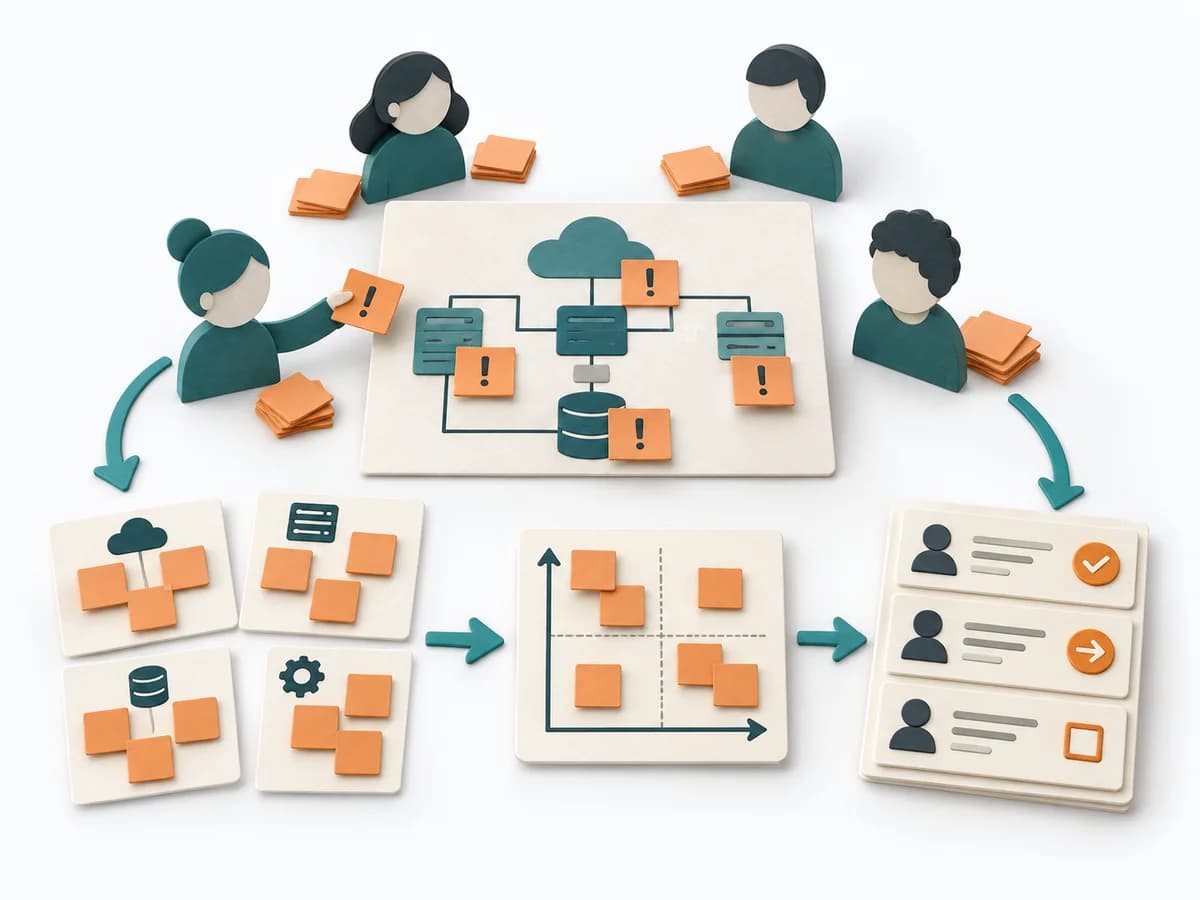 Architecture Risk Storming |
|---|---|---|---|
Purposedifferent | The C4 Model makes a system legible across several resolution levels, from context down to code. It suits situations where different audiences need to understand the same architecture from different altitudes. | On complex initiatives, a plain average tends to understate just how uncertain the outcome really is. It separates options, evaluation criteria, and open risks. The result is captured as a PERT Estimate, Expected Value, and Risk Notes. | Helps clarify architecture context, options, and consequences in concrete terms. It organizes technical context, alternatives, and consequences. The result is captured as an Annotated Diagram, a Prioritized Risk List, and an Action Backlog. |
Complexitydifferent | Low | Medium | Low |
Timedifferent | 1-4 h | 15-45 min | 60-90 min |
Participantsdifferent | 1-5 | 1-8 | 4-12 |
Formatdifferent | Workshop + async | Workshop + async | Workshop |
Outputdifferent | Context Diagram, Container Diagram, Component Diagram | PERT Estimate, Expected Value, Risk Notes | Annotated Diagram, Prioritized Risk List, Action Backlog |
Tagsno overlap | ArchitectureCommunicationVisualization | EstimationUncertaintyRisk | RiskArchitectureWorkshopValidation |
Often compared together
Methods with strong topical overlap with the current selection, not yet in the comparison.