View methods side by side.
Choose up to four methods. Add them using the search and share the comparison by copying its link.
| Criterion |  Delivery MoSCoW | 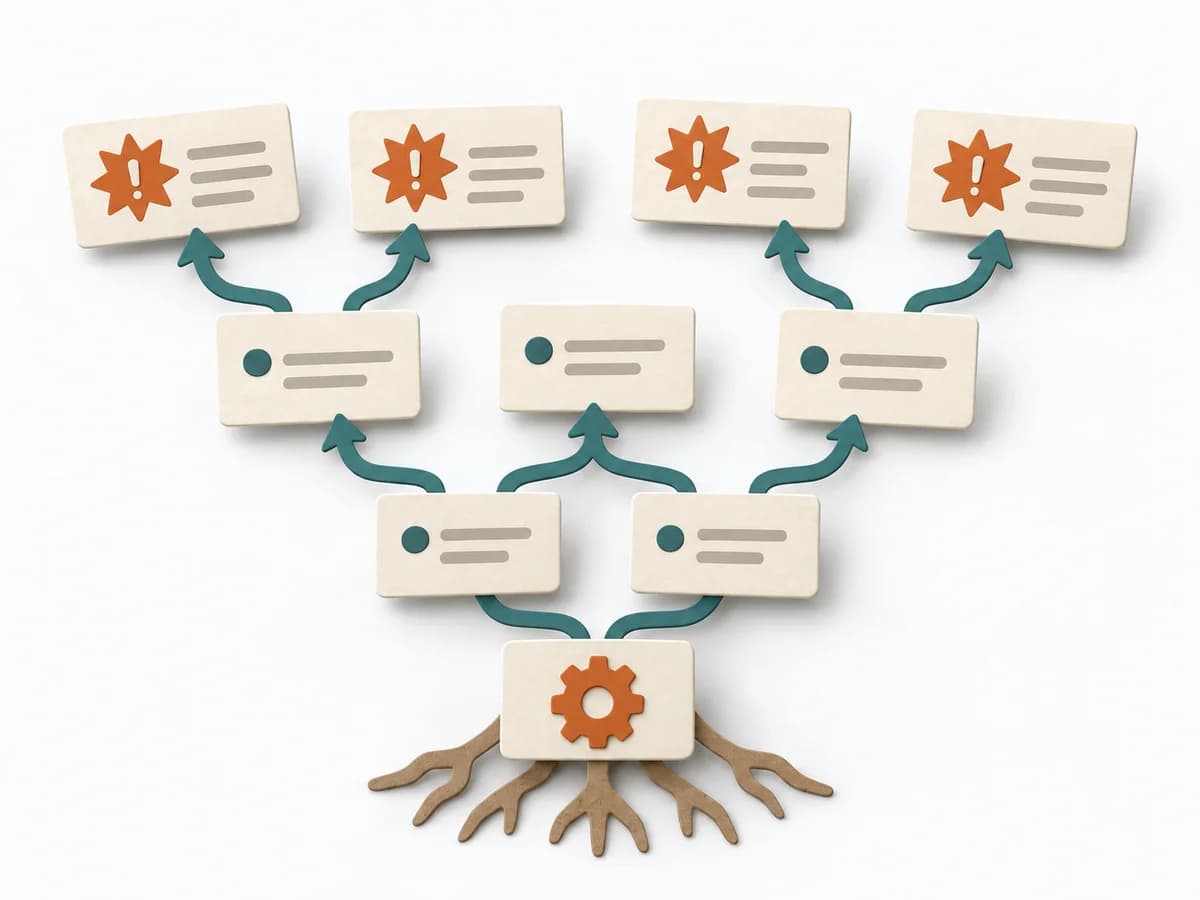 Systems Thinking Current Reality Tree | 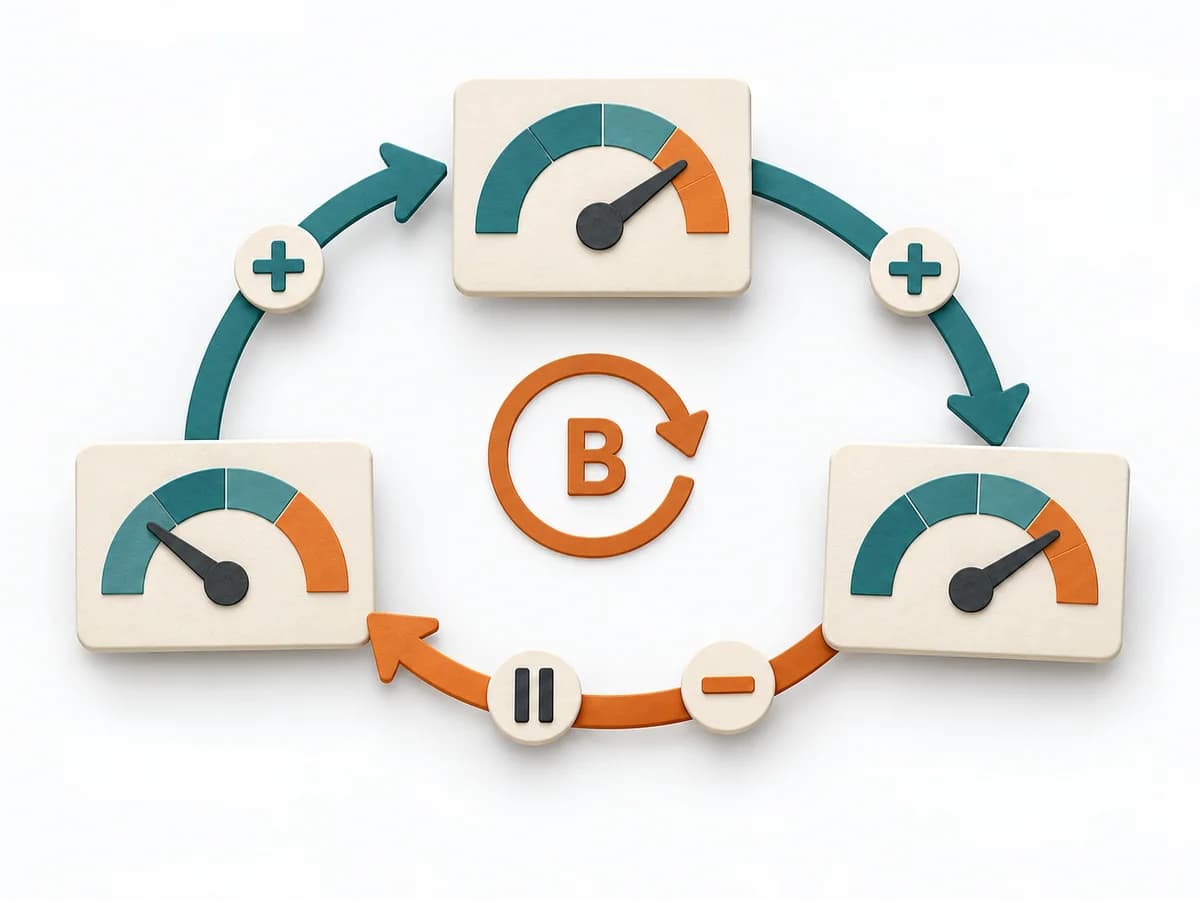 Systems Thinking Causal Loop Diagram |
|---|---|---|---|
Purposedifferent | When a release carries too many demands and priorities are only ever negotiated, MoSCoW creates clear boundaries for the next cut. Must, Should, Could, and Won't make commitment, room for maneuver, and trade-off logic visible to everyone involved. | A Current Reality Tree condenses many symptoms into a few causal chains. The method makes visible which core problems drive several negative effects at once. | A Causal Loop Diagram makes feedback, reinforcement, and balance in a system legible. It uncovers side effects and self-reinforcement that stay hidden in linear explanations. |
Complexitydifferent | Low | High | Medium |
Timedifferent | 30-90 min | 2-6 h | 1-3 h |
Participantsdifferent | 3-12 | 3-8 | 2-8 |
Formatdifferent | Workshop + async | Workshop | Workshop |
Outputdifferent | Prioritized Backlog, Release Scope, Tradeoff Notes | Current Reality Tree, Core Problems, Intervention Ideas | Causal Loop Diagram, Feedback Notes, Leverage Points |
Tagsno overlap | PrioritizationScopeDecision | Systems thinkingRoot causeConstraintsCausality | FeedbackSystems thinkingCausalityDynamics |
Often compared together
Methods with strong topical overlap with the current selection, not yet in the comparison.