View methods side by side.
Choose up to four methods. Add them using the search and share the comparison by copying its link.
| Criterion |  Delivery MoSCoW | 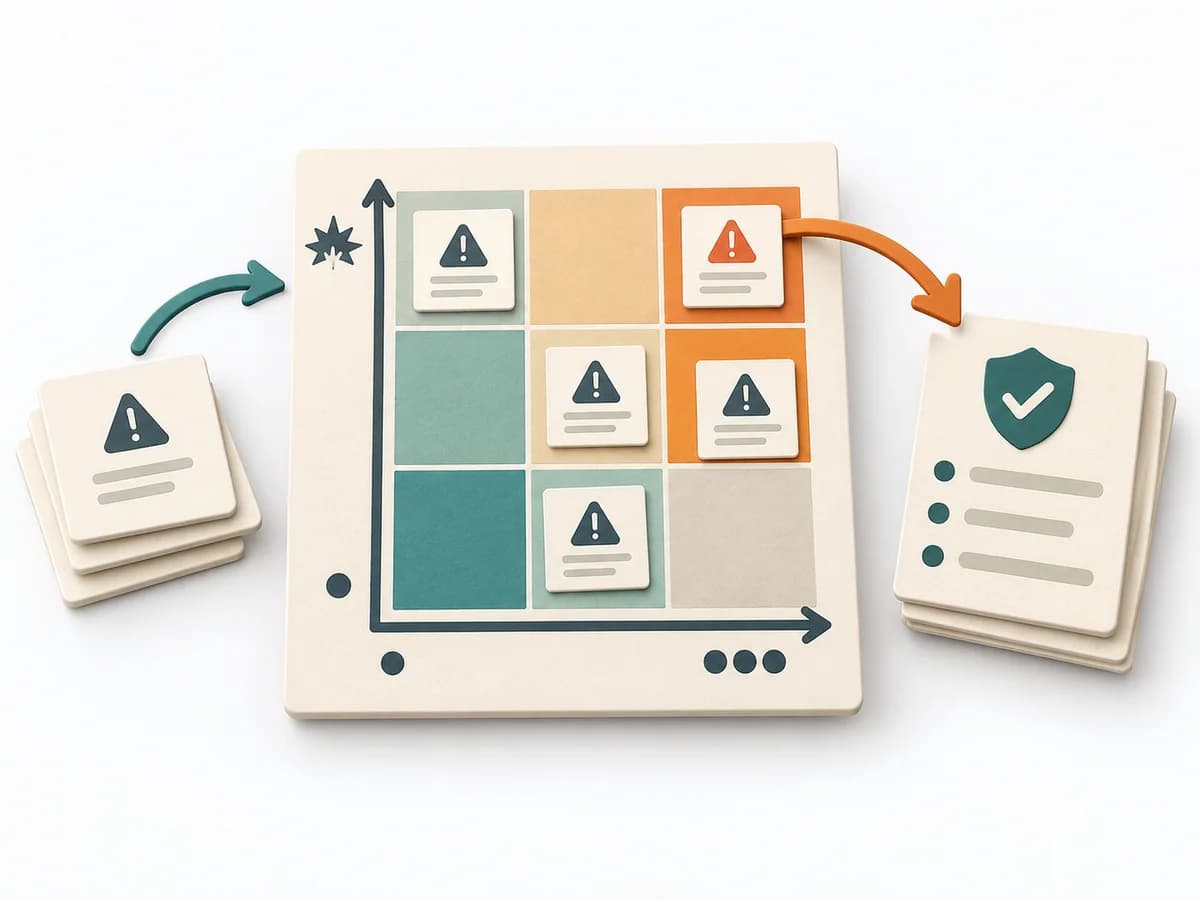 Decision Making Risk Matrix | 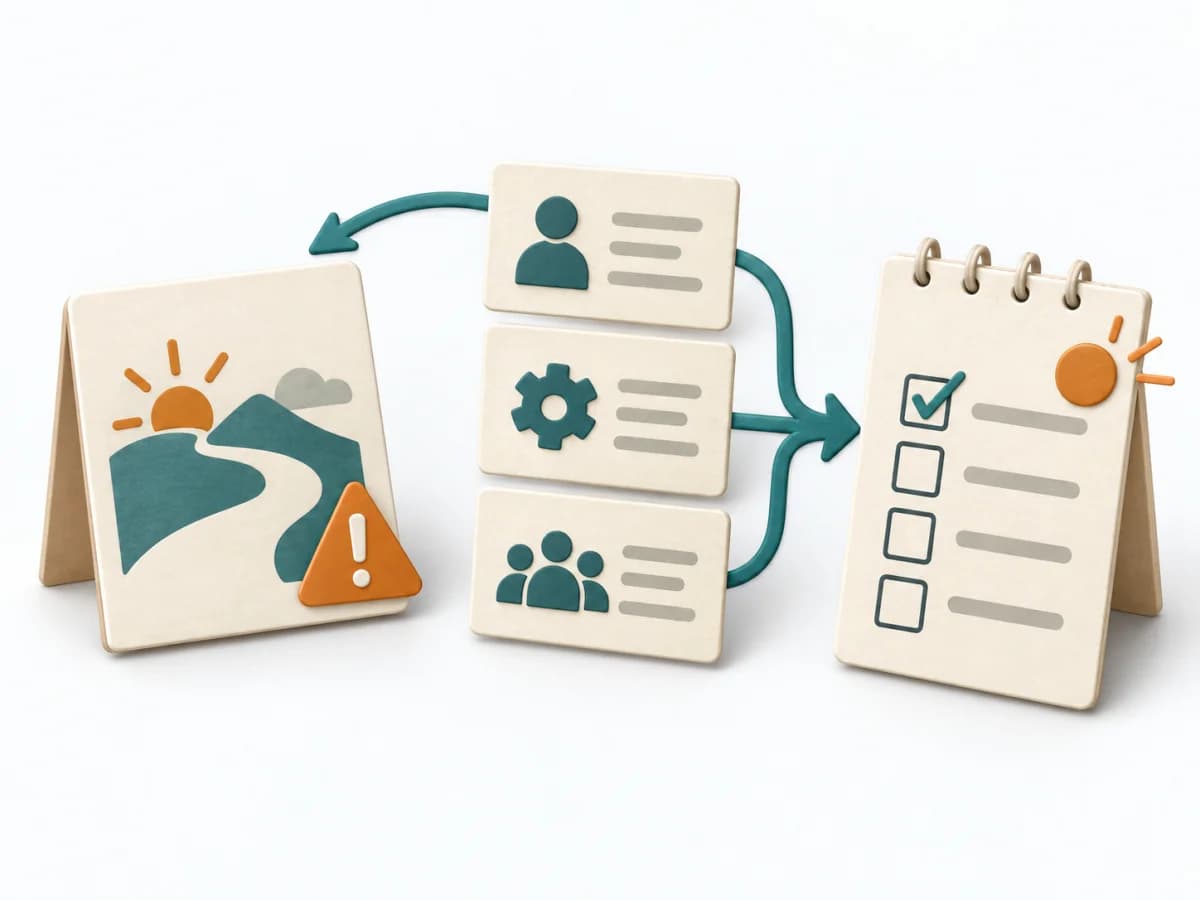 Decision Making Pre-Mortem | 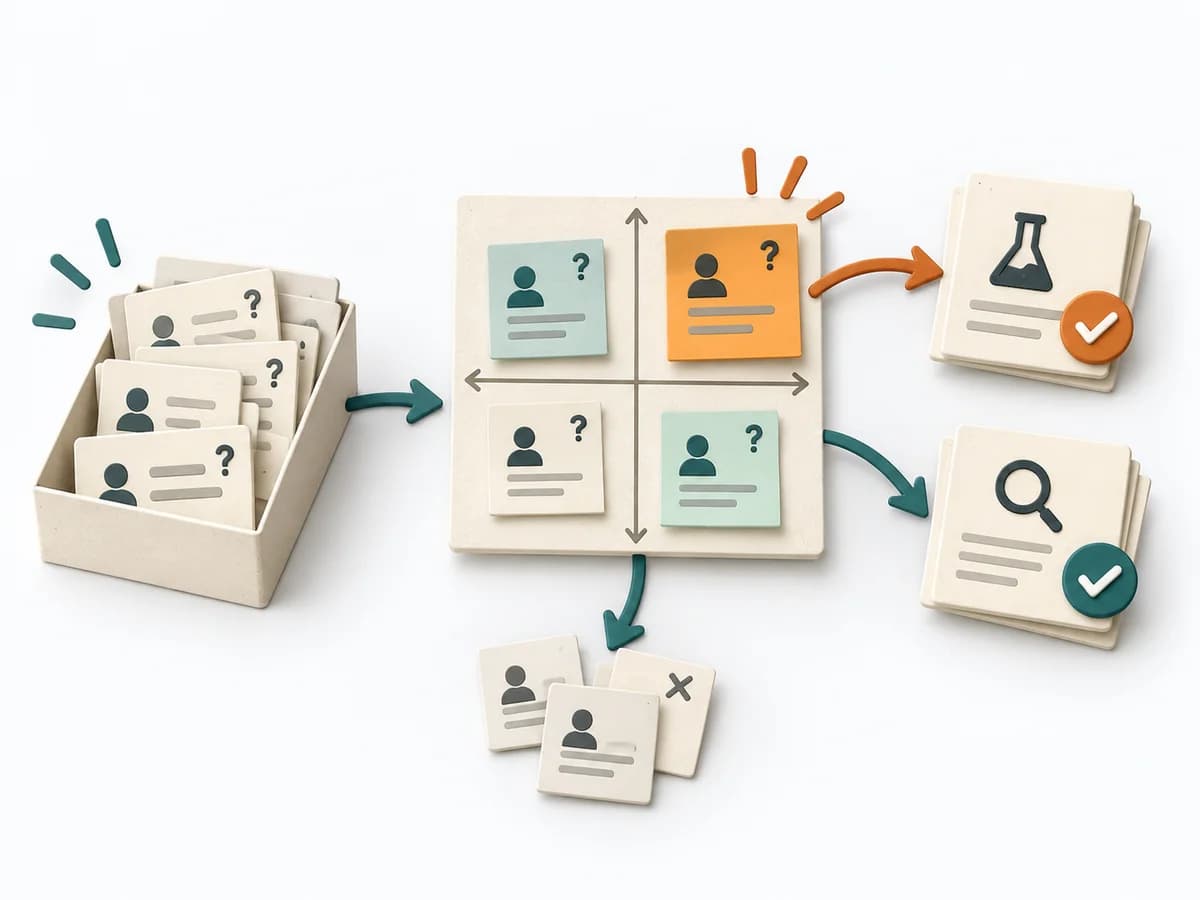 Decision Making Assumption Surfacing |
|---|---|---|---|---|
Purposedifferent | When a release carries too many demands and priorities are only ever negotiated, MoSCoW creates clear boundaries for the next cut. Must, Should, Could, and Won't make commitment, room for maneuver, and trade-off logic visible to everyone involved. | When a project faces many possible disruptions, it quickly becomes unclear which risks deserve attention first. It separates options, evaluation criteria, and open risks. The result is captured as a Risk Matrix and a Top Risk List. | In early initiatives with many uncertainties, planning quickly turns too optimistic. A pre-mortem makes the expected failure visible in advance and sharpens the view of causes, gaps, and countermeasures. | Plans often contain assumptions that were never openly stated and remain dangerous precisely because of that. Assumption Surfacing makes these silent premises visible and prioritizes which of them carry the initiative or could sink it. |
Complexitysame | Low | Low | Low | Low |
Timedifferent | 30-90 min | 30-60 min | 20–45 min | 45-90 min |
Participantsdifferent | 3-12 | 3-10 | Small cross-functional group | 2-8 |
Formatdifferent | Workshop + async | Workshop + async | Workshop | Workshop + async |
Outputdifferent | Prioritized Backlog, Release Scope, Tradeoff Notes | Risk Matrix, Top Risk List | Risk list, Mitigation plan, Assumption log | Assumption List, Critical Assumptions, Learning Plan |
Tags1 shared | PrioritizationScopeDecision | RiskDecisionPrioritizationAssessment | RiskDecisionFailurePlanning | AssumptionsRiskDecisionDiscovery |