View methods side by side.
Choose up to four methods. Add them using the search and share the comparison by copying its link.
| Criterion |  Delivery MoSCoW | 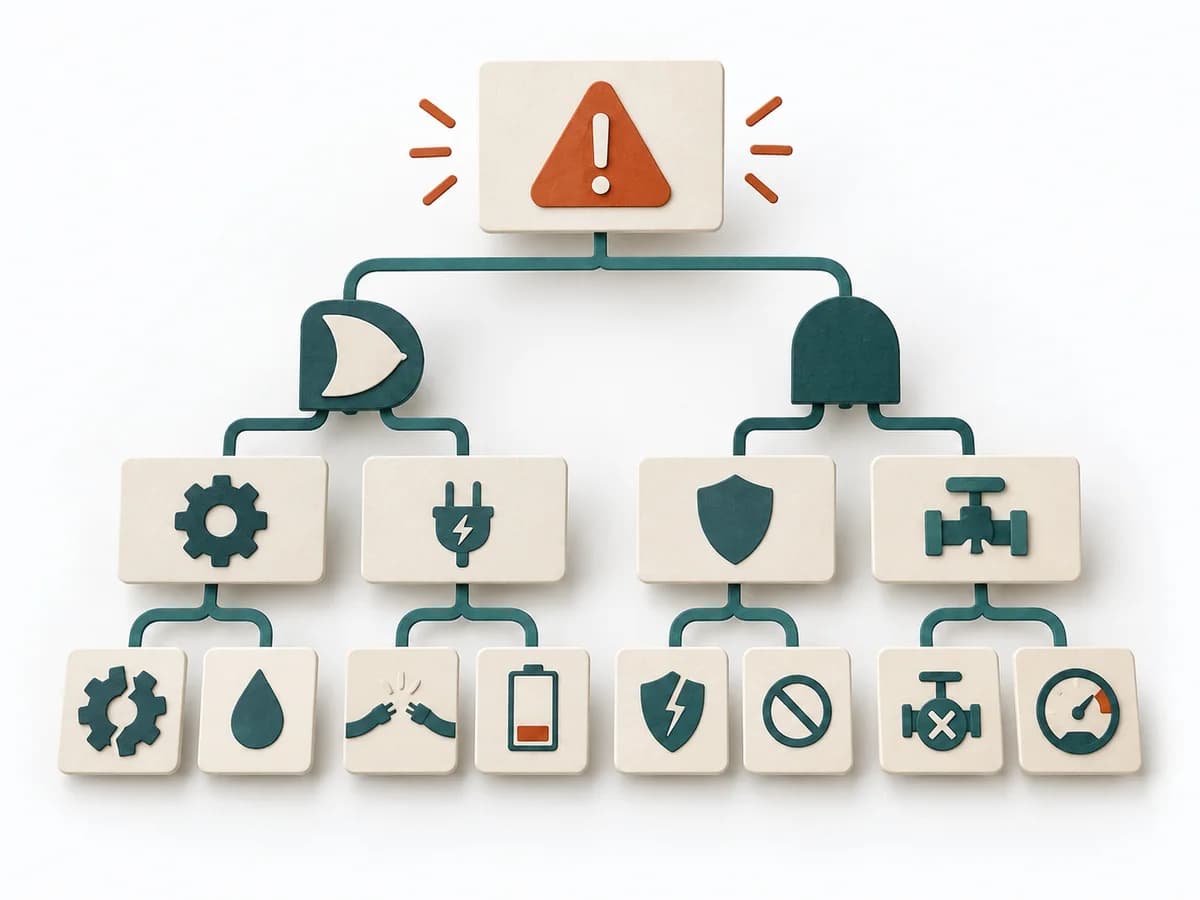 Operations Fault Tree Analysis | 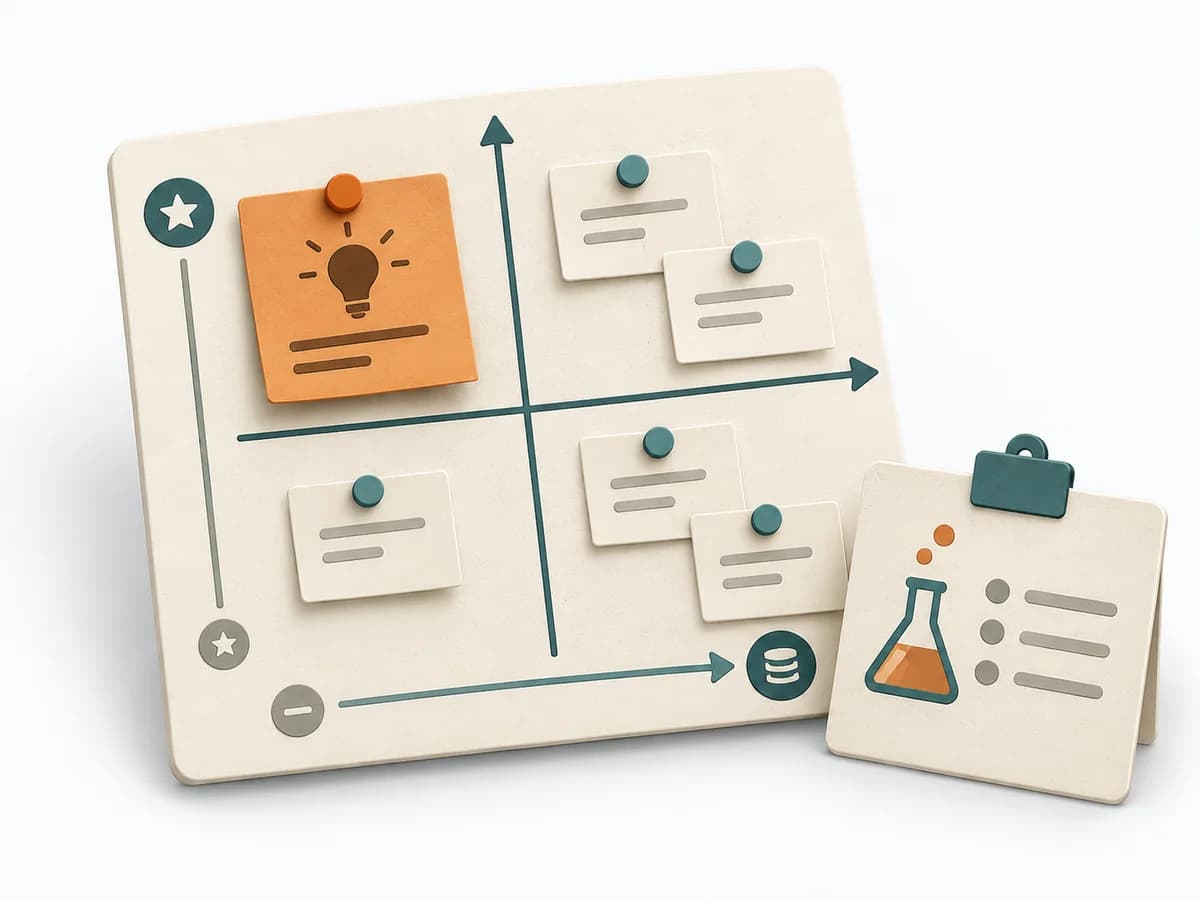 Product Discovery Assumption Mapping | 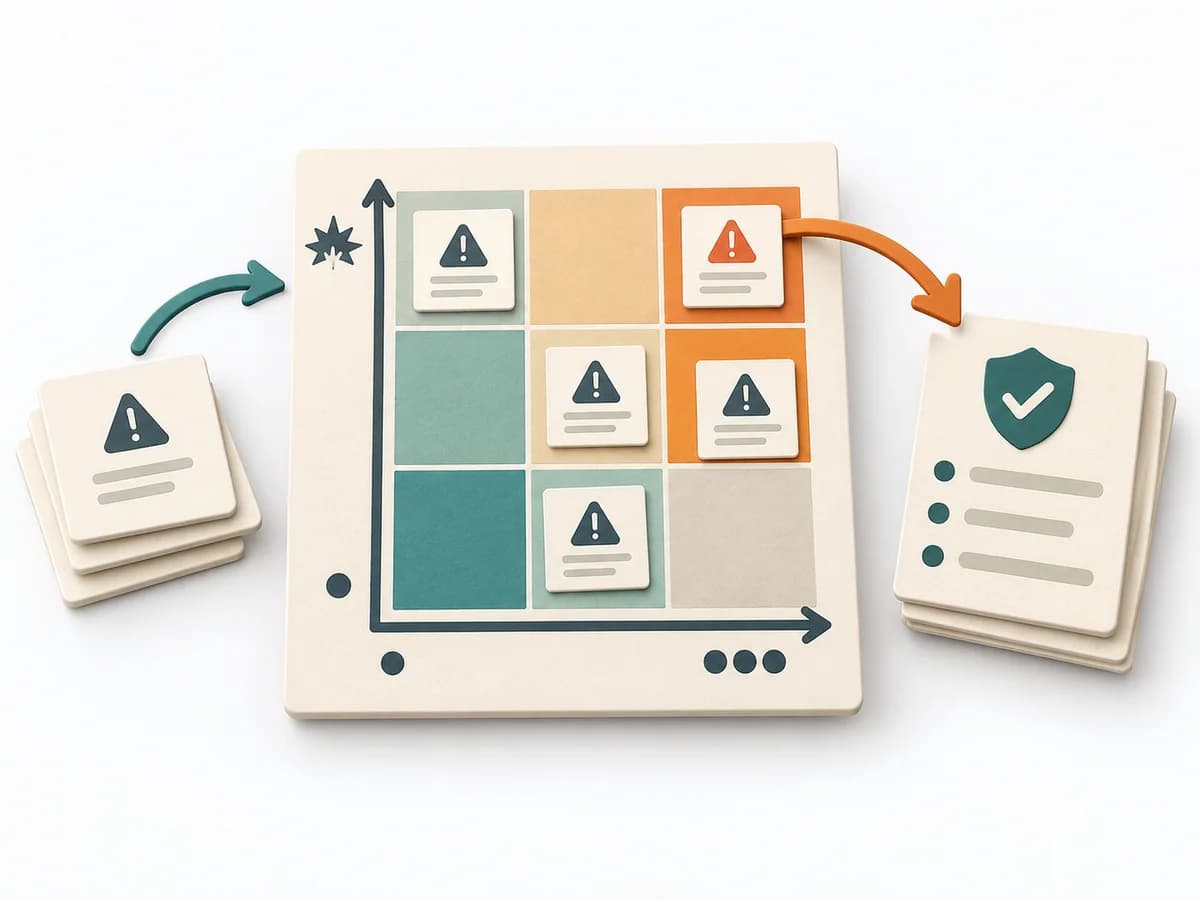 Decision Making Risk Matrix |
|---|---|---|---|---|
Purposedifferent | When a release carries too many demands and priorities are only ever negotiated, MoSCoW creates clear boundaries for the next cut. Must, Should, Could, and Won't make commitment, room for maneuver, and trade-off logic visible to everyone involved. | For a critical top event with several possible triggers, the method logically models failure paths. It makes visible which combinations of conditions can lead to damage. | When assumptions still sit unordered in the room, it weighs uncertainty against leverage. It makes visible which hypotheses should be checked first. | When a project faces many possible disruptions, it quickly becomes unclear which risks deserve attention first. It separates options, evaluation criteria, and open risks. The result is captured as a Risk Matrix and a Top Risk List. |
Complexitydifferent | Low | High | Medium | Low |
Timedifferent | 30-90 min | 2-6 h | 45-60 min | 30-60 min |
Participantsdifferent | 3-12 | 3-8 | 2-8 | 3-10 |
Formatsame | Workshop + async | Workshop + async | Workshop + async | Workshop + async |
Outputdifferent | Prioritized Backlog, Release Scope, Tradeoff Notes | Fault Tree, Critical Paths, Cause Hypotheses, Control Actions | Assumption map, Test backlog, Risk ranking | Risk Matrix, Top Risk List |
Tagsno overlap | PrioritizationScopeDecision | RiskRoot causeSafety | AssumptionsRiskExperimentsValidation | RiskDecisionPrioritizationAssessment |