View methods side by side.
Choose up to four methods. Add them using the search and share the comparison by copying its link.
| Criterion |  Delivery MoSCoW | 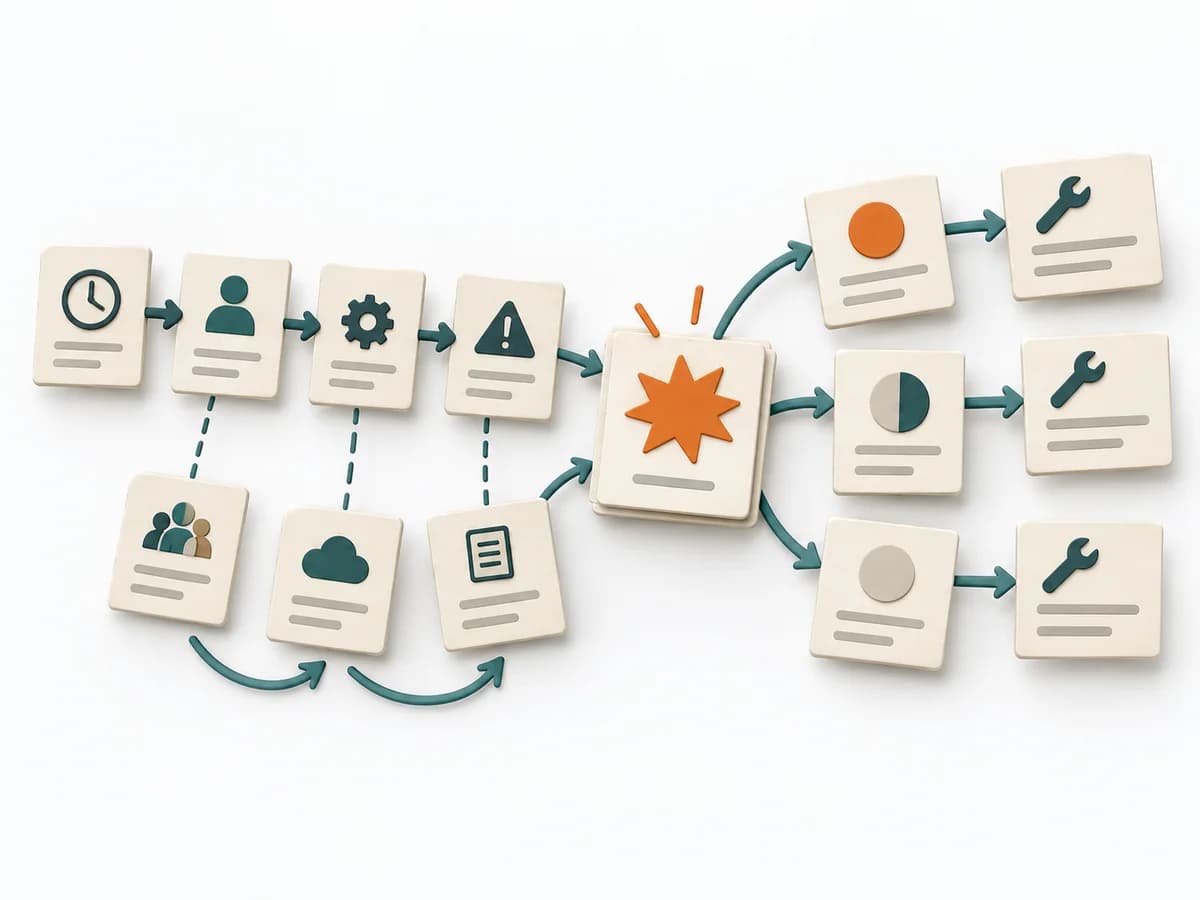 Operations Causal Factor Analysis | 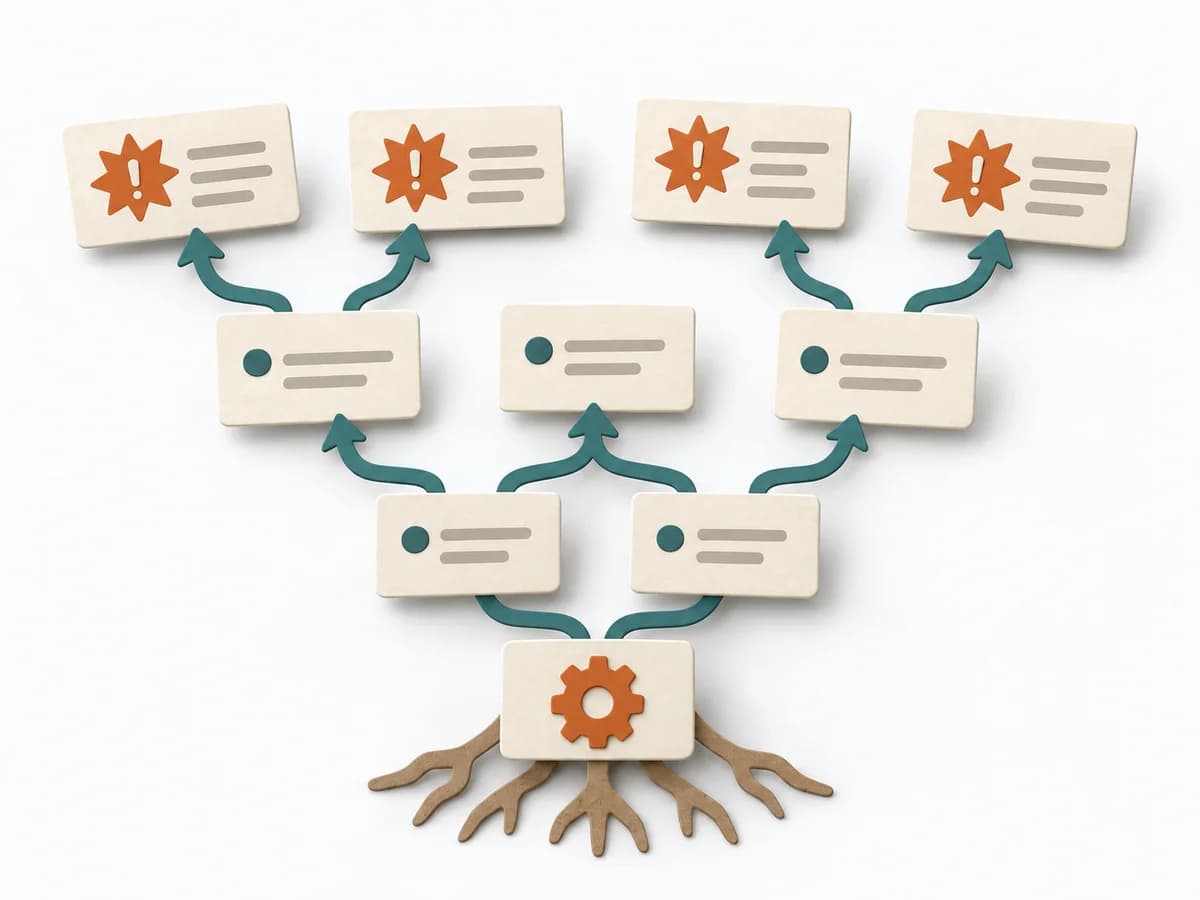 Systems Thinking Current Reality Tree | 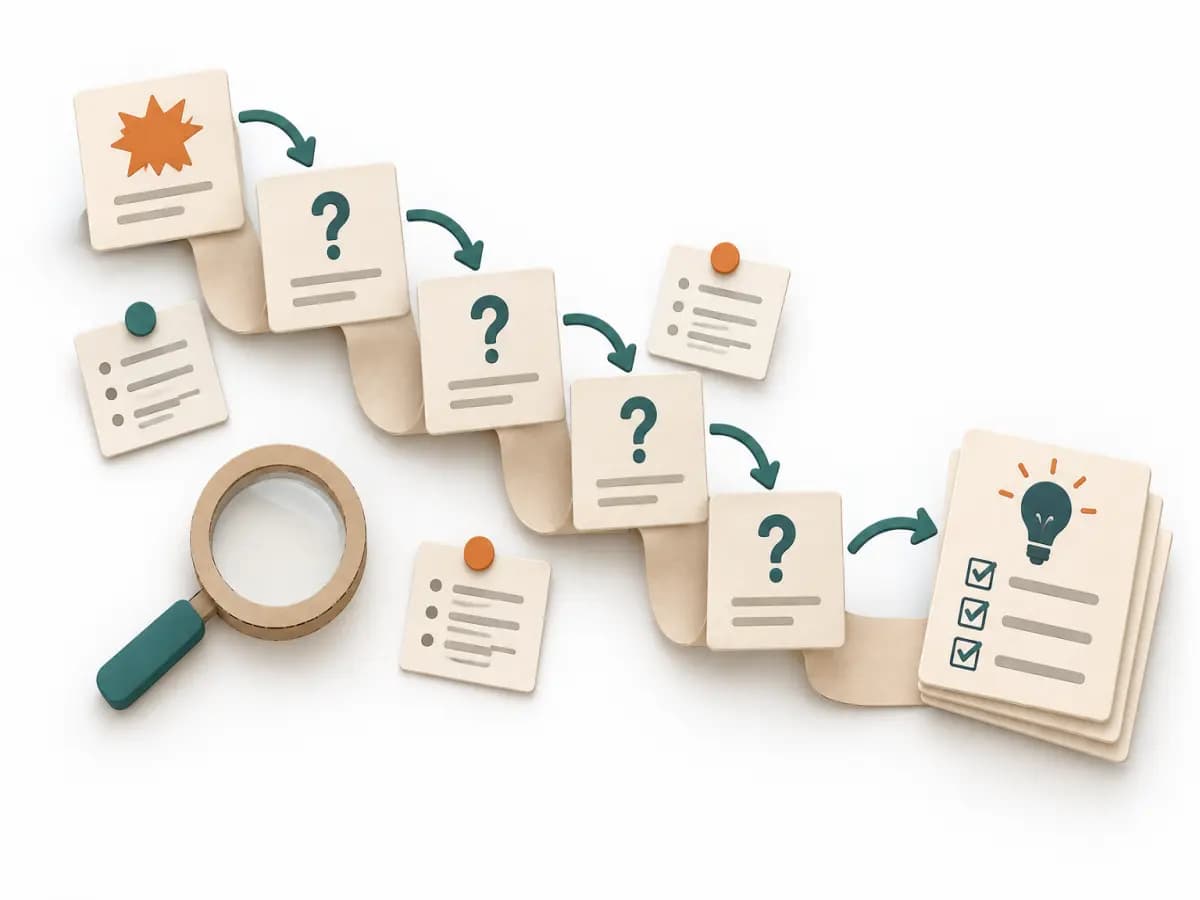 Operations 5 Whys |
|---|---|---|---|---|
Purposedifferent | When a release carries too many demands and priorities are only ever negotiated, MoSCoW creates clear boundaries for the next cut. Must, Should, Could, and Won't make commitment, room for maneuver, and trade-off logic visible to everyone involved. | For an event with a complicated course, the method breaks down the contributing factors along the timeline. It shows how conditions, decisions, and reactions together produce a course of events. | A Current Reality Tree condenses many symptoms into a few causal chains. The method makes visible which core problems drive several negative effects at once. | For a single, hard-to-explain deviation, the method exposes the causal chain behind the visible symptom. It keeps the cause open until a controllable condition emerges instead of a mere description. |
Complexitydifferent | Low | High | High | Low |
Timedifferent | 30-90 min | 2-6 h | 2-6 h | 15-30 min |
Participantsdifferent | 3-12 | 3-10 | 3-8 | 2-6 |
Formatdifferent | Workshop + async | Workshop + async | Workshop | Workshop |
Outputdifferent | Prioritized Backlog, Release Scope, Tradeoff Notes | Event Timeline, Causal Factor Chart, Cause List, Corrective Actions | Current Reality Tree, Core Problems, Intervention Ideas | Root cause notes, Countermeasures |
Tagsno overlap | PrioritizationScopeDecision | CausalityIncidentRoot causeTimeline | Systems thinkingRoot causeConstraintsCausality | Root causeIncidentLeanProblem solving |