View methods side by side.
Choose up to four methods. Add them using the search and share the comparison by copying its link.
| Criterion | 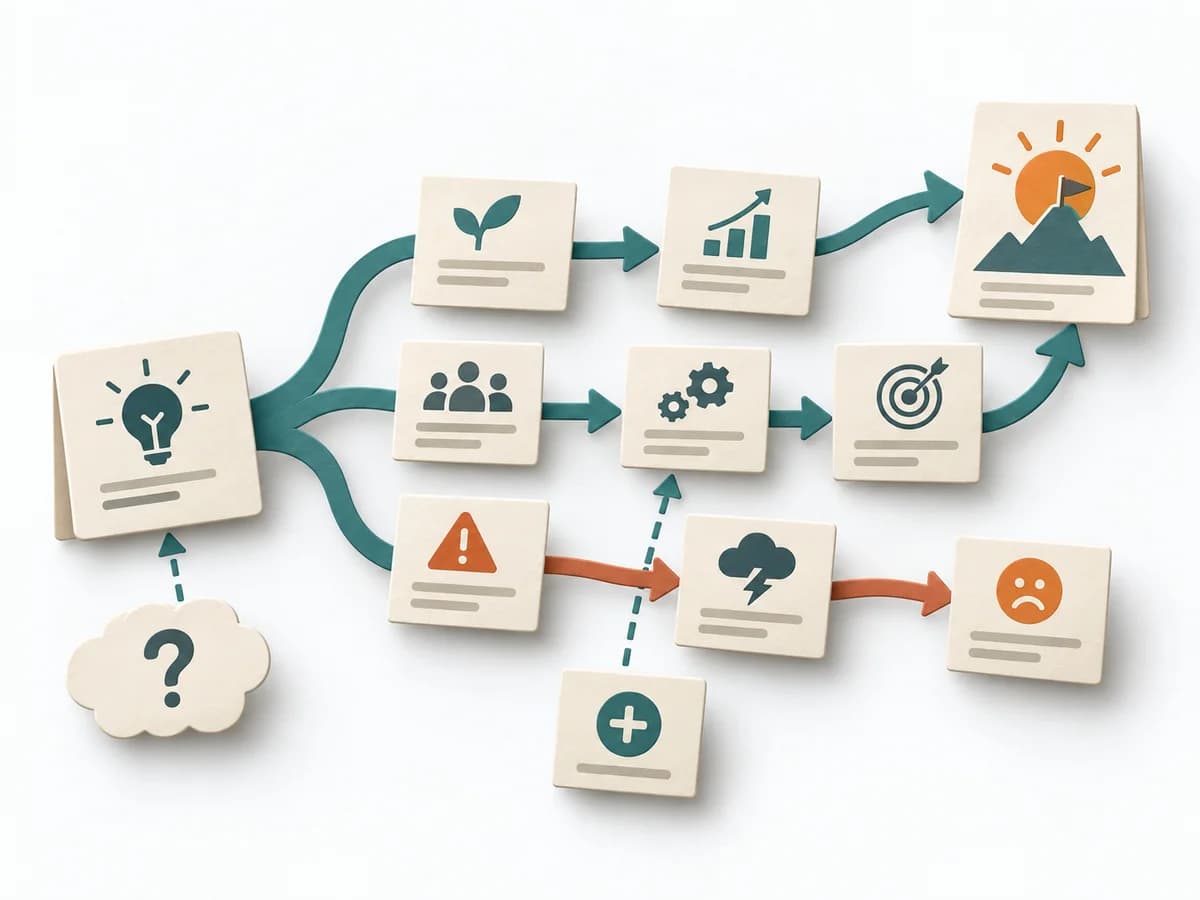 Systems Thinking Future Reality Tree | 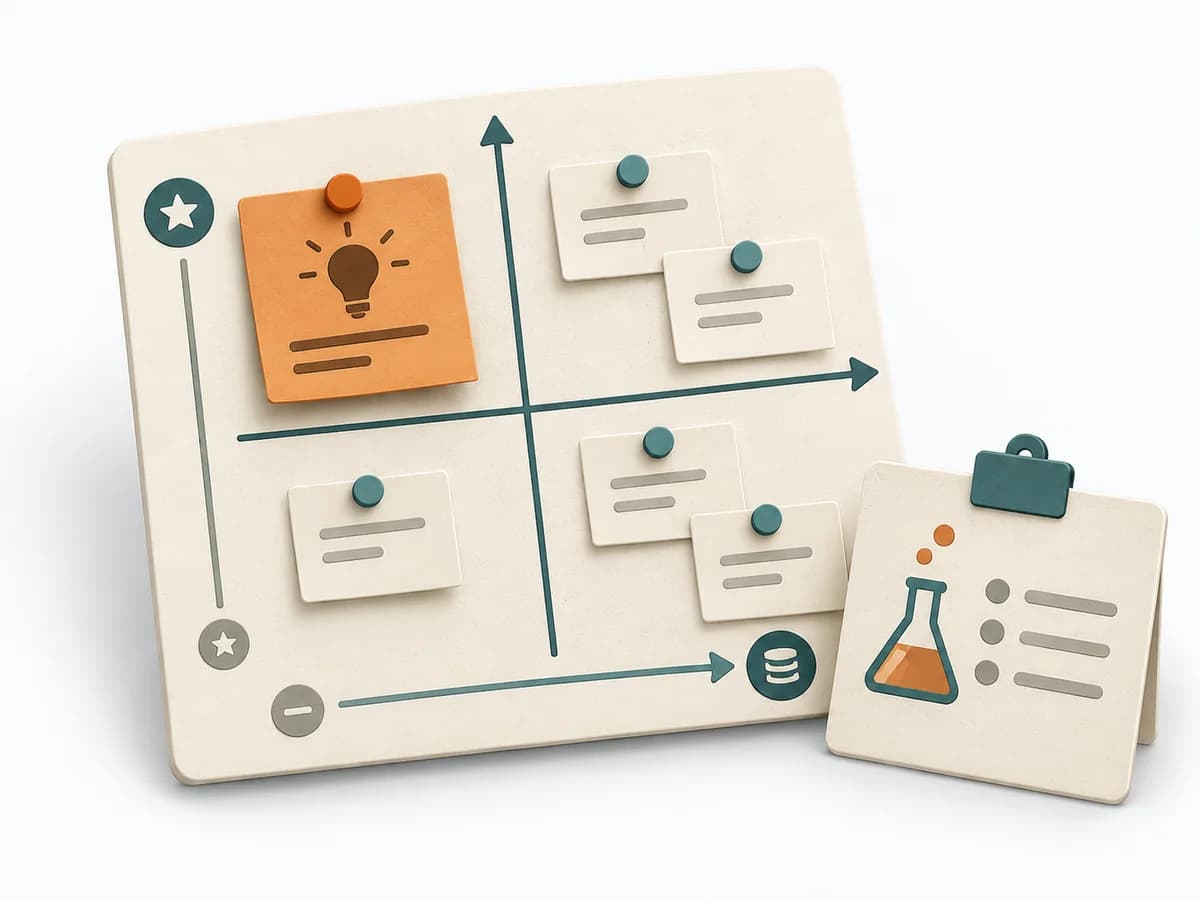 Product Discovery Assumption Mapping | 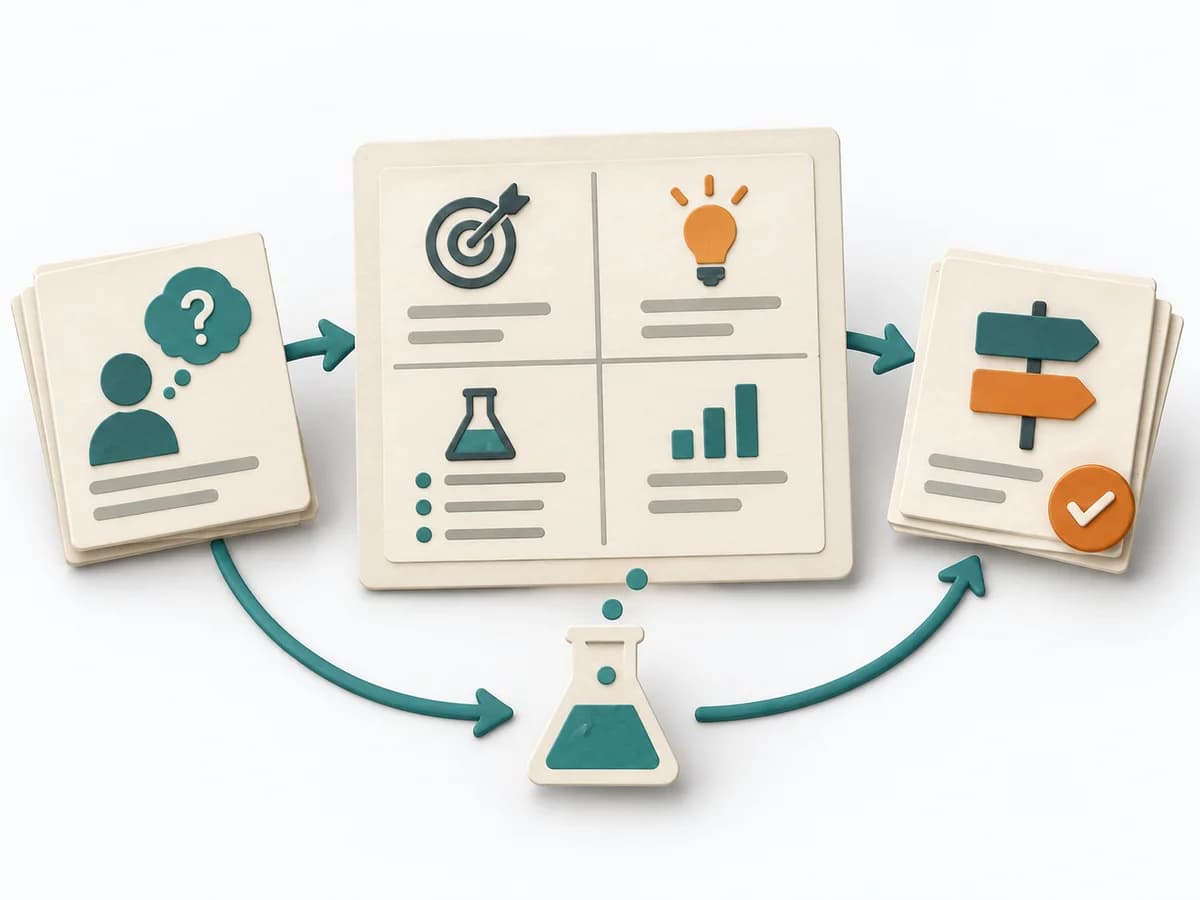 Product Discovery Experiment Canvas | 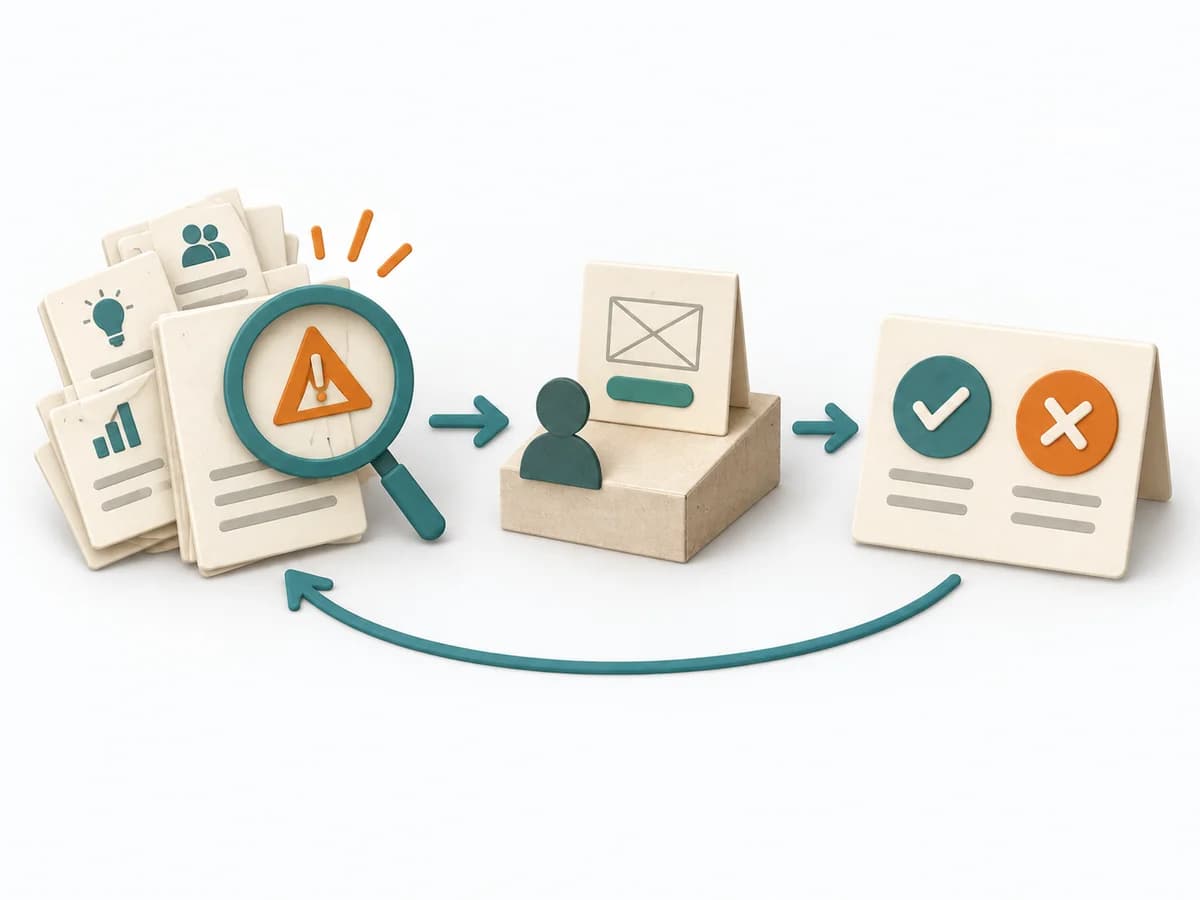 Product Discovery Riskiest Assumption Test |
|---|---|---|---|---|
Purposedifferent | A Future Reality Tree shows how desired actions are meant to lead to a better system state. The method checks whether a path of change holds together logically before time flows into implementation. | When assumptions still sit unordered in the room, it weighs uncertainty against leverage. It makes visible which hypotheses should be checked first. | When experiments become unreadable after the fact, it arranges hypothesis, signal, and learning goal on a single canvas. It separates problem, assumption, solution, and evidence. The result is captured as a Completed Experiment Canvas and a Success Metric. | When an idea hinges on one critical unknown, it prioritizes testing that exact piece of uncertainty first. It separates problem, assumption, solution, and evidence. The result is captured as a prioritized list of assumptions, a test plan, and a result report. |
Complexitydifferent | High | Medium | Low | Medium |
Timedifferent | 2-4 h | 45-60 min | 30-60 min | 1-2 Wochen pro Iteration |
Participantsdifferent | 3-8 | 2-8 | 1-5 | 2-6 |
Formatdifferent | Workshop | Workshop + async | Workshop + async | Workshop + async |
Outputdifferent | Future Reality Tree, Negative Branches, Assumption List, Improved Injections | Assumption map, Test backlog, Risk ranking | Completed Experiment Canvas, Success Metric | Prioritized Assumption List, Test Plan, Results Report |
Tagsno overlap | Theory of ConstraintsSystems thinkingChange | AssumptionsRiskExperimentsValidation | ExperimentsValidationDiscoveryHypothesis | ExperimentsValidationDiscoveryAssumptions |