View methods side by side.
Choose up to four methods. Add them using the search and share the comparison by copying its link.
| Criterion | 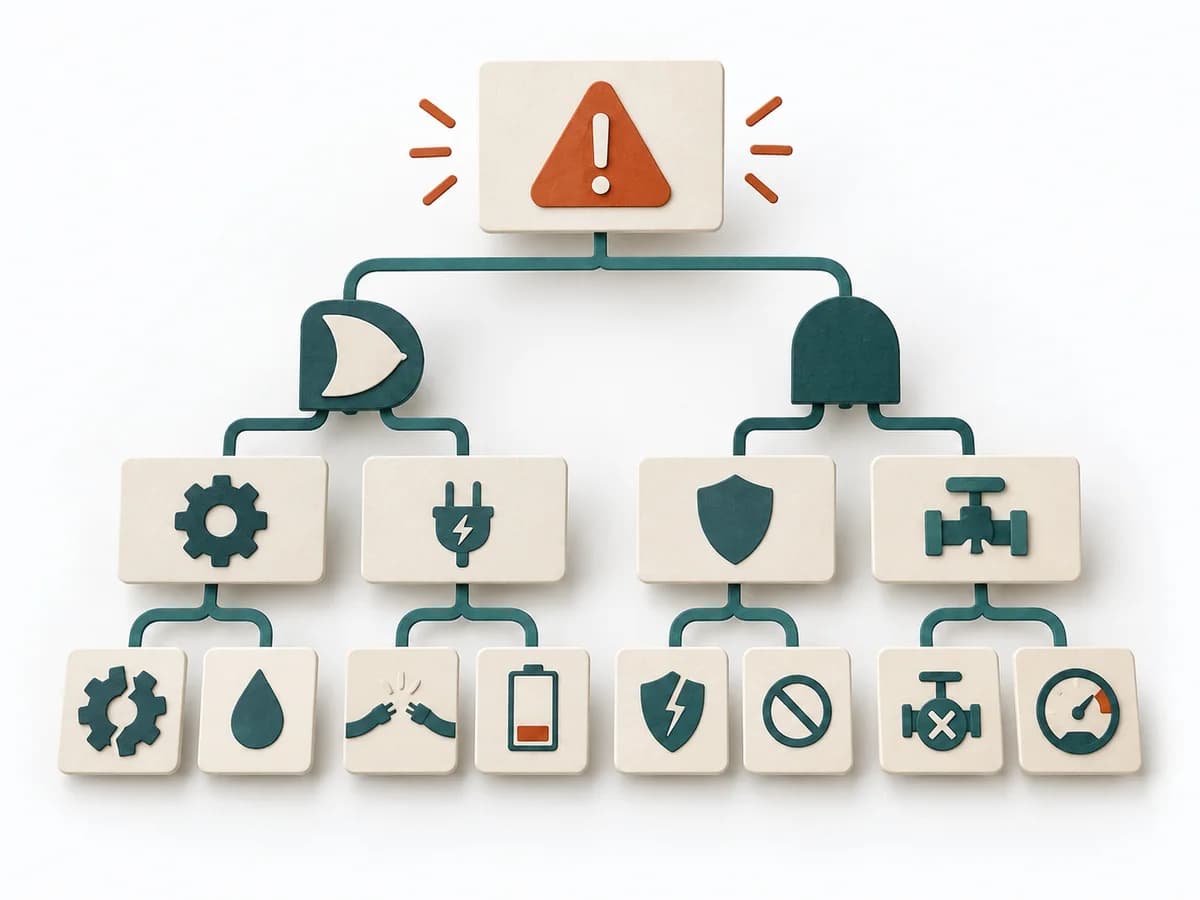 Operations Fault Tree Analysis | 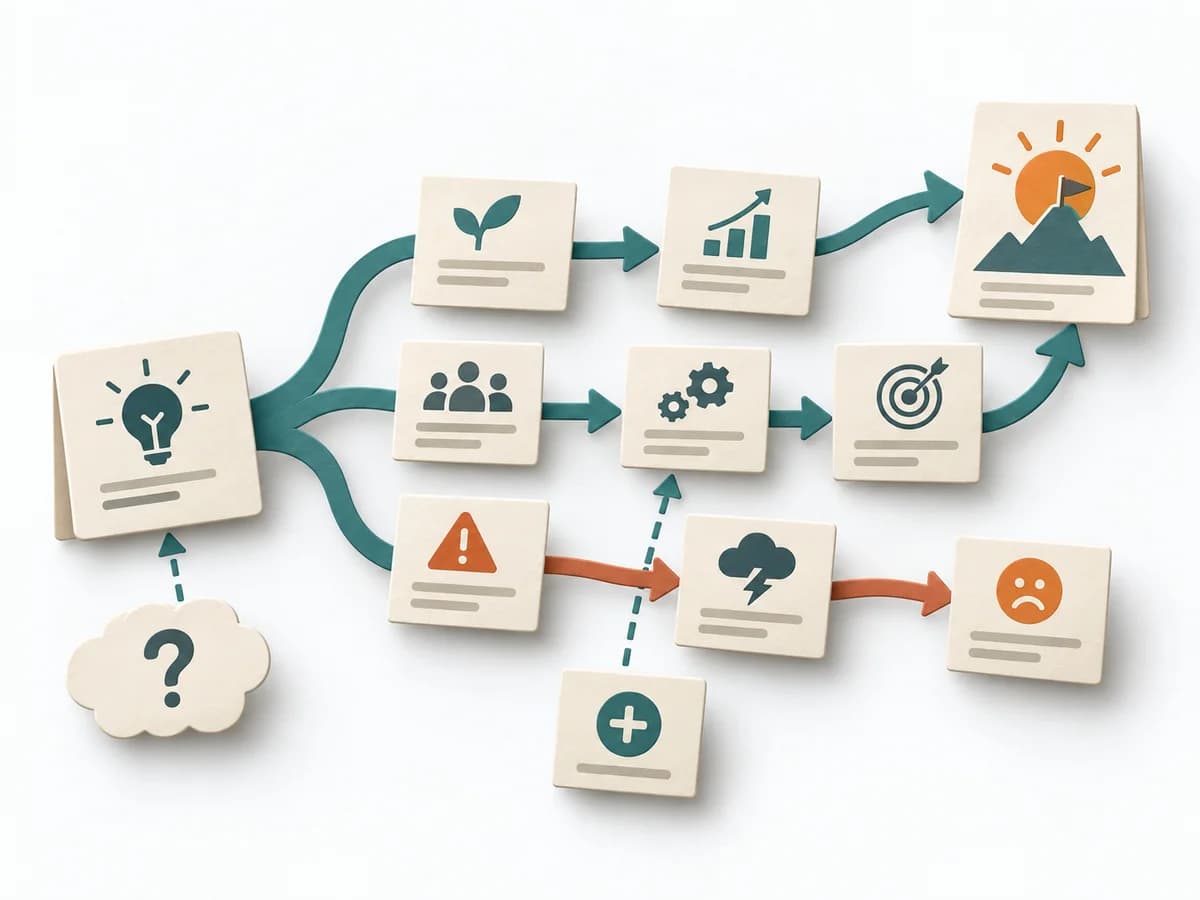 Systems Thinking Future Reality Tree | 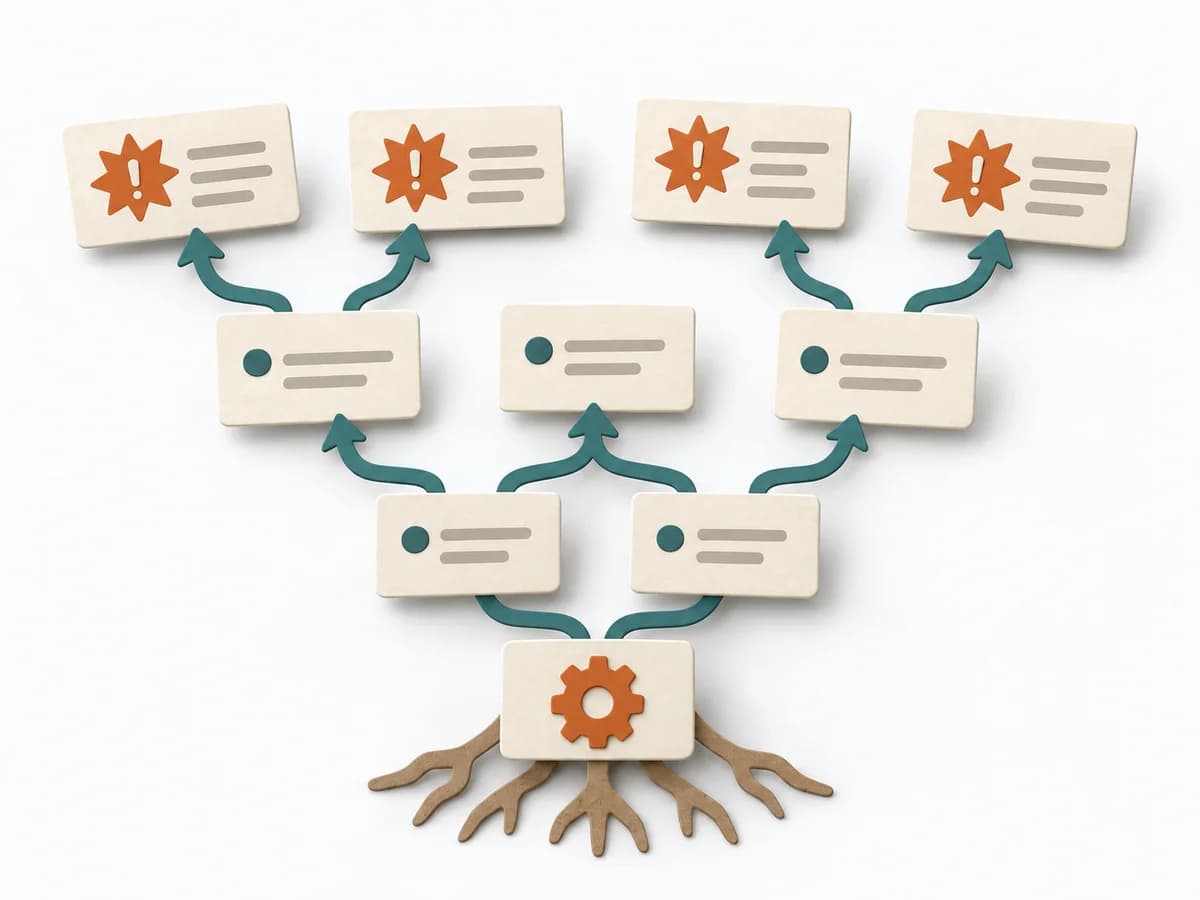 Systems Thinking Current Reality Tree | 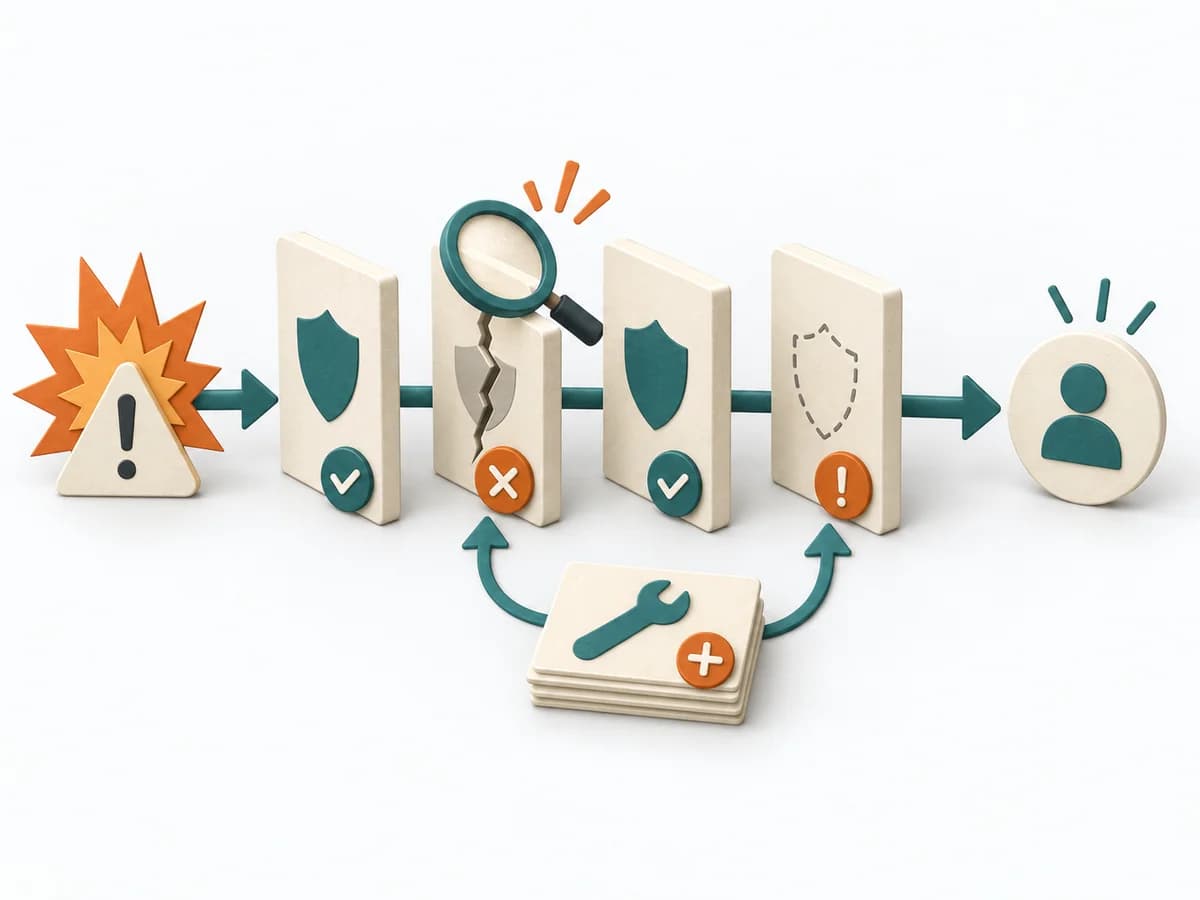 Operations Barrier Analysis |
|---|---|---|---|---|
Purposedifferent | For a critical top event with several possible triggers, the method logically models failure paths. It makes visible which combinations of conditions can lead to damage. | A Future Reality Tree shows how desired actions are meant to lead to a better system state. The method checks whether a path of change holds together logically before time flows into implementation. | A Current Reality Tree condenses many symptoms into a few causal chains. The method makes visible which core problems drive several negative effects at once. | For a risk that can only be managed through multiple layers of protection, the method examines the effectiveness of each barrier. It shows where safeguards are missing, too weak, or fail under real conditions. |
Complexitydifferent | High | High | High | Medium |
Timedifferent | 2-6 h | 2-4 h | 2-6 h | 2-4 h |
Participantsdifferent | 3-8 | 3-8 | 3-8 | 2-6 |
Formatdifferent | Workshop + async | Workshop | Workshop | Workshop + async |
Outputdifferent | Fault Tree, Critical Paths, Cause Hypotheses, Control Actions | Future Reality Tree, Negative Branches, Assumption List, Improved Injections | Current Reality Tree, Core Problems, Intervention Ideas | Barrier Inventory, Failure Analysis per Barrier, Action Backlog |
Tagsno overlap | RiskRoot causeSafety | Theory of ConstraintsSystems thinkingChange | Systems thinkingRoot causeConstraintsCausality | Root causeSafetyIncident |