View methods side by side.
Choose up to four methods. Add them using the search and share the comparison by copying its link.
| Criterion | 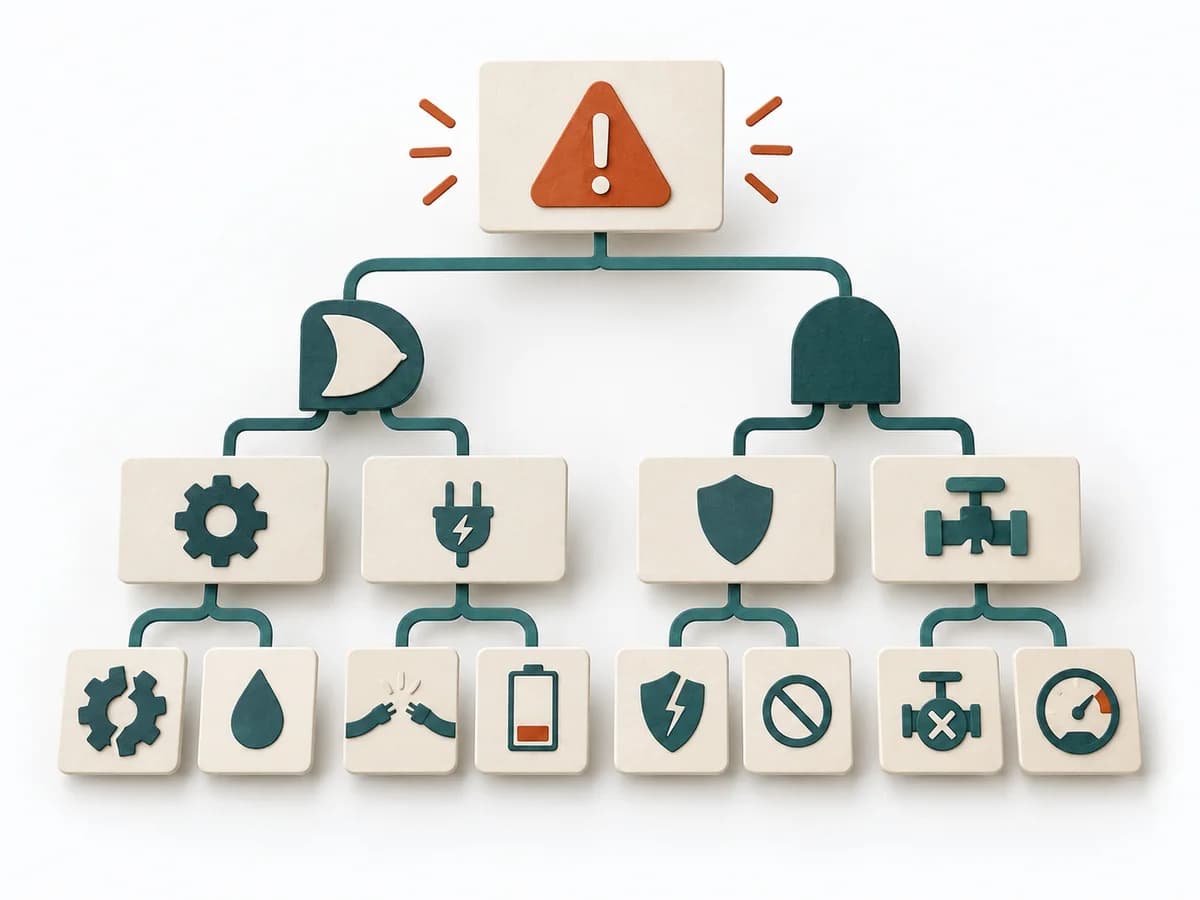 Operations Fault Tree Analysis | 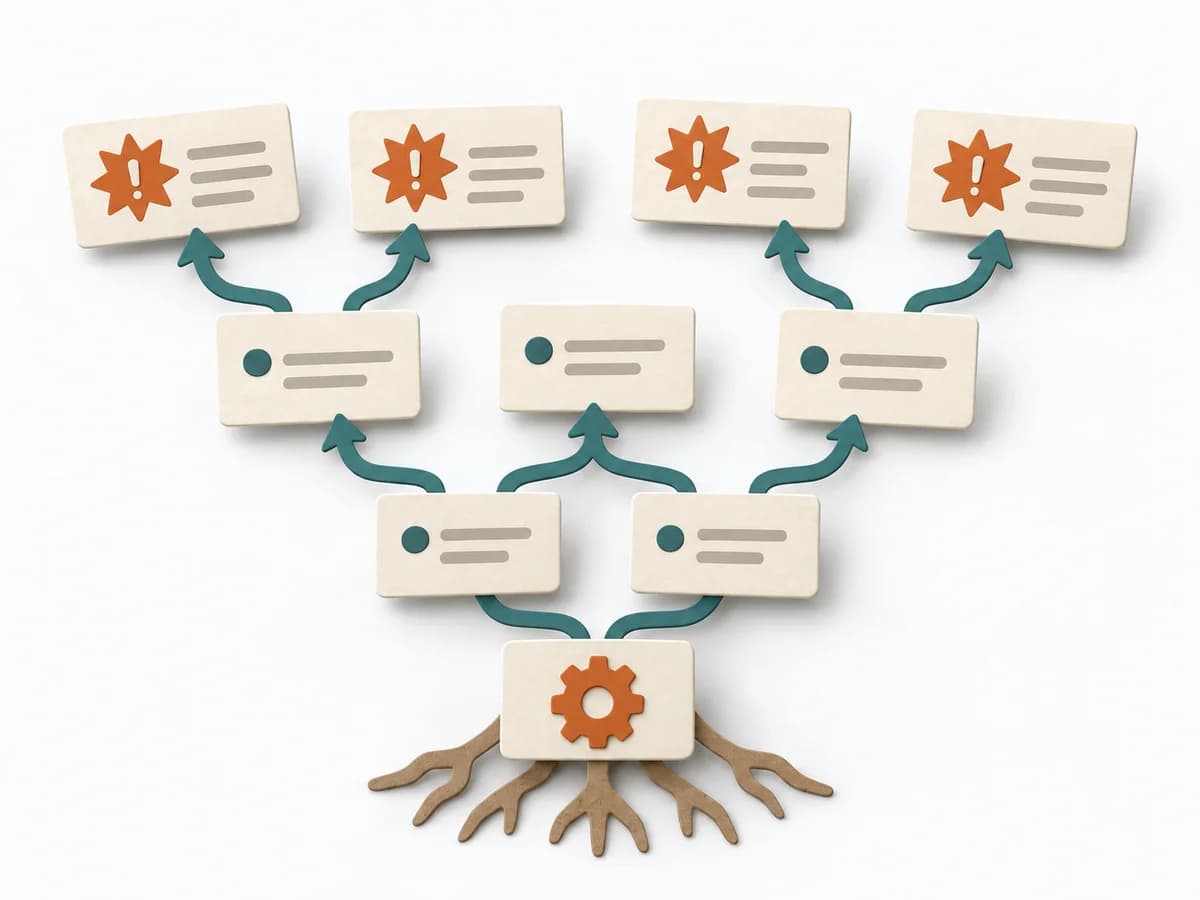 Systems Thinking Current Reality Tree | 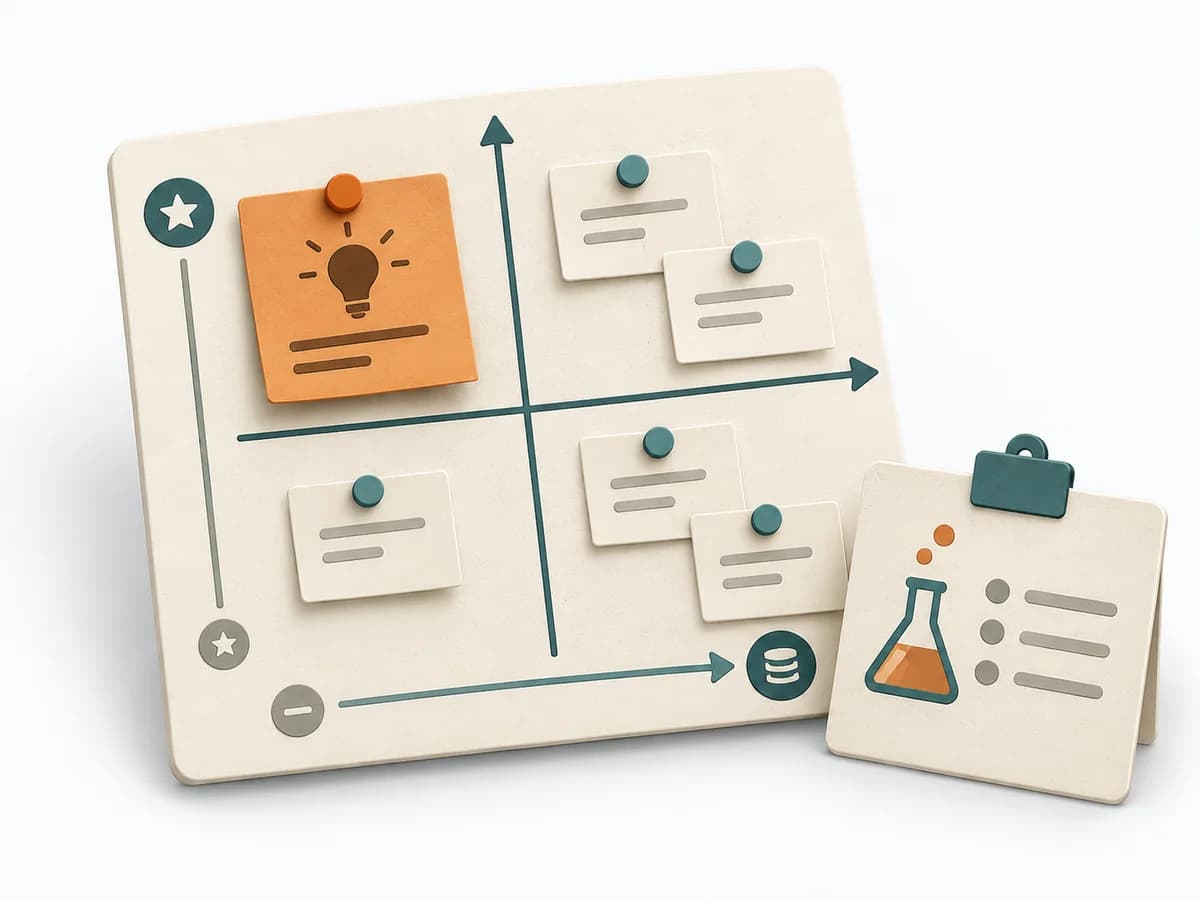 Product Discovery Assumption Mapping | 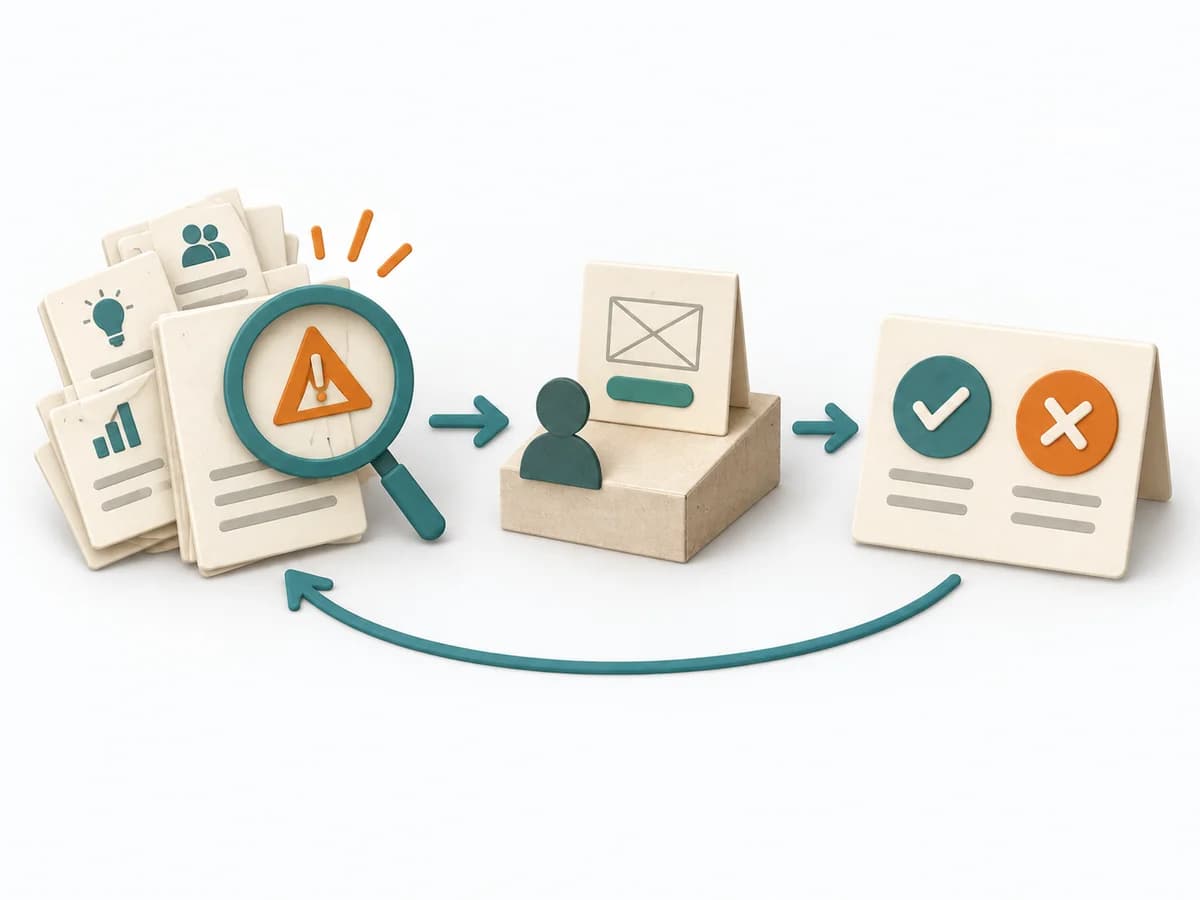 Product Discovery Riskiest Assumption Test |
|---|---|---|---|---|
Purposedifferent | For a critical top event with several possible triggers, the method logically models failure paths. It makes visible which combinations of conditions can lead to damage. | A Current Reality Tree condenses many symptoms into a few causal chains. The method makes visible which core problems drive several negative effects at once. | When assumptions still sit unordered in the room, it weighs uncertainty against leverage. It makes visible which hypotheses should be checked first. | When an idea hinges on one critical unknown, it prioritizes testing that exact piece of uncertainty first. It separates problem, assumption, solution, and evidence. The result is captured as a prioritized list of assumptions, a test plan, and a result report. |
Complexitydifferent | High | High | Medium | Medium |
Timedifferent | 2-6 h | 2-6 h | 45-60 min | 1-2 Wochen pro Iteration |
Participantsdifferent | 3-8 | 3-8 | 2-8 | 2-6 |
Formatdifferent | Workshop + async | Workshop | Workshop + async | Workshop + async |
Outputdifferent | Fault Tree, Critical Paths, Cause Hypotheses, Control Actions | Current Reality Tree, Core Problems, Intervention Ideas | Assumption map, Test backlog, Risk ranking | Prioritized Assumption List, Test Plan, Results Report |
Tagsno overlap | RiskRoot causeSafety | Systems thinkingRoot causeConstraintsCausality | AssumptionsRiskExperimentsValidation | ExperimentsValidationDiscoveryAssumptions |